Now
What I'm currently building. Newest first.
-
Isaac: two-tree release sequence passes
Job 21328323: 20 seconds, 17/17 independent checks, one gated spur release, 809.49 mm measured fall, home error under 0.001 mm. Closure failure from 7.7 s stays public. Still one known target, not a success rate.
-
Humanoid: first sign of life
Cables dressed on 6 Sep. Onboard computer on 7 Sep; LiDAR and stereo on the robot on 8 Sep. Resoldered disconnected motors on 9 Sep, then motor diagnostics on the onboard computer on 10 Sep. Fully built on 12 Sep. First sign of life on 13 Sep.
13 Sep — First sign of life. 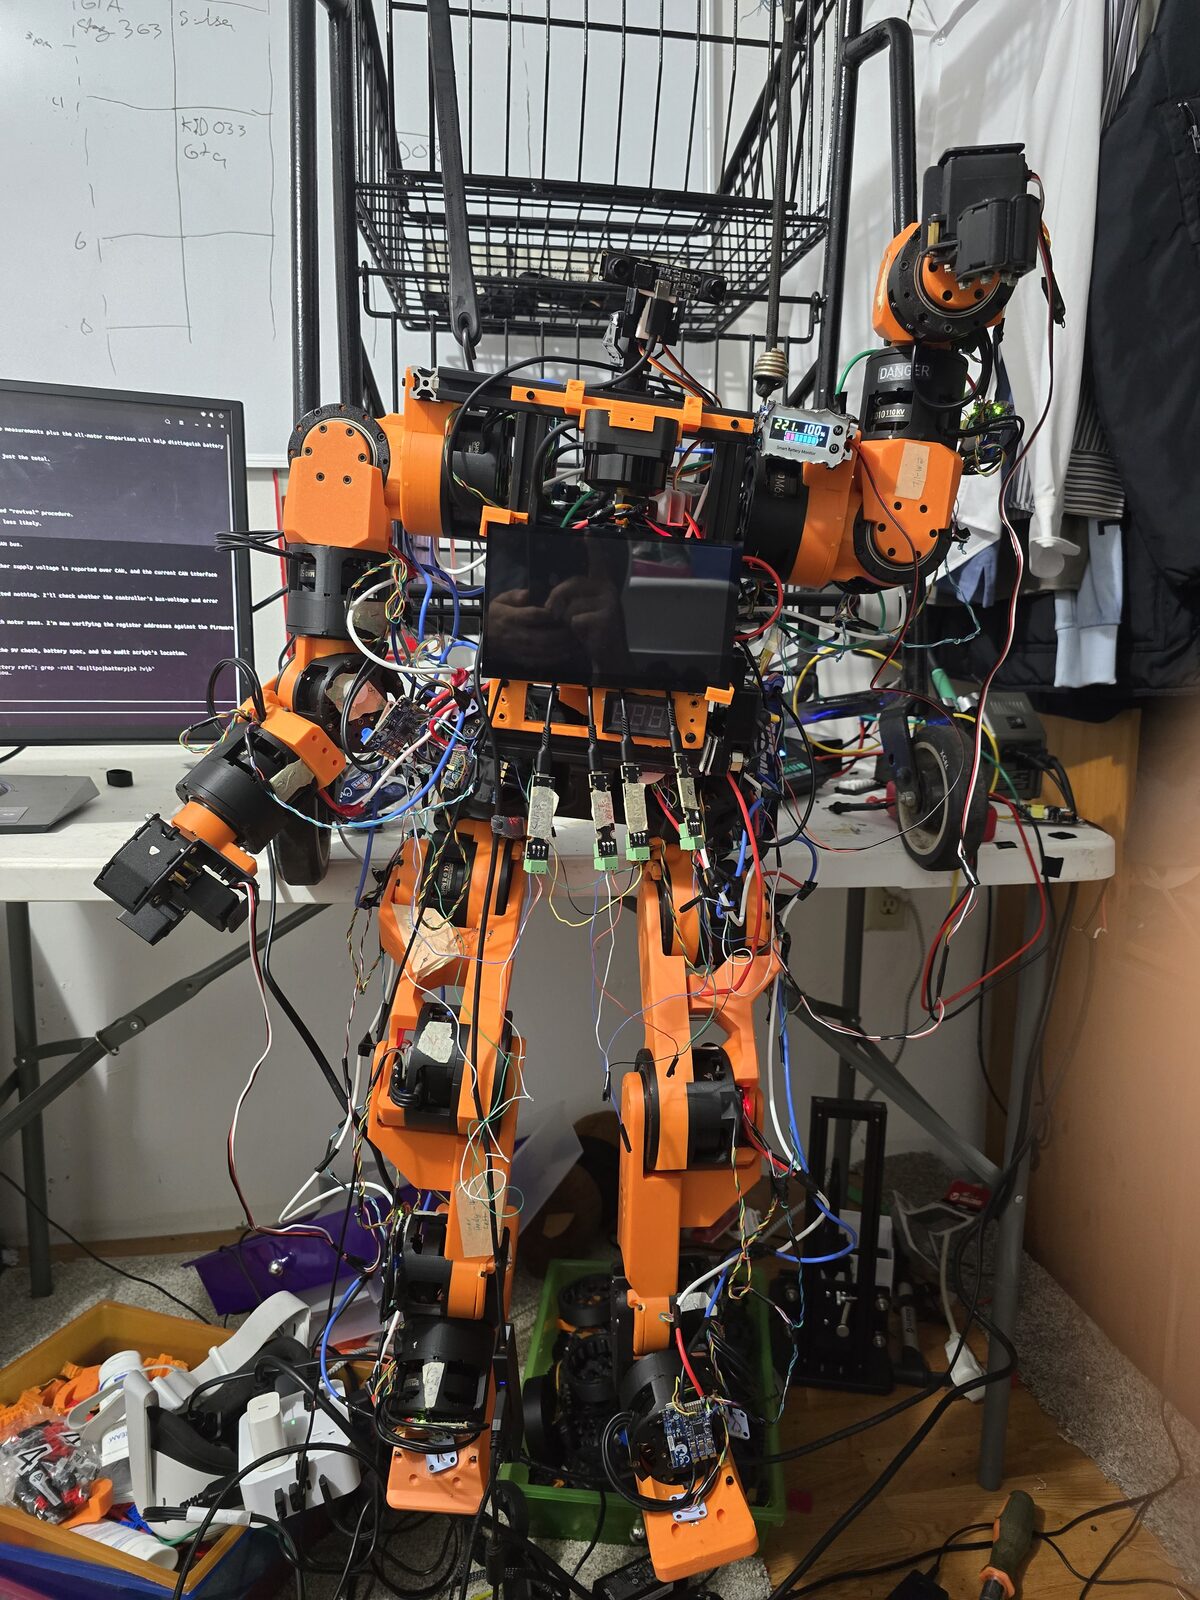
12 Sep — Fully built robot. Working on getting movement. 10 Sep — Running diagnostic on onboard computer to configure motors. 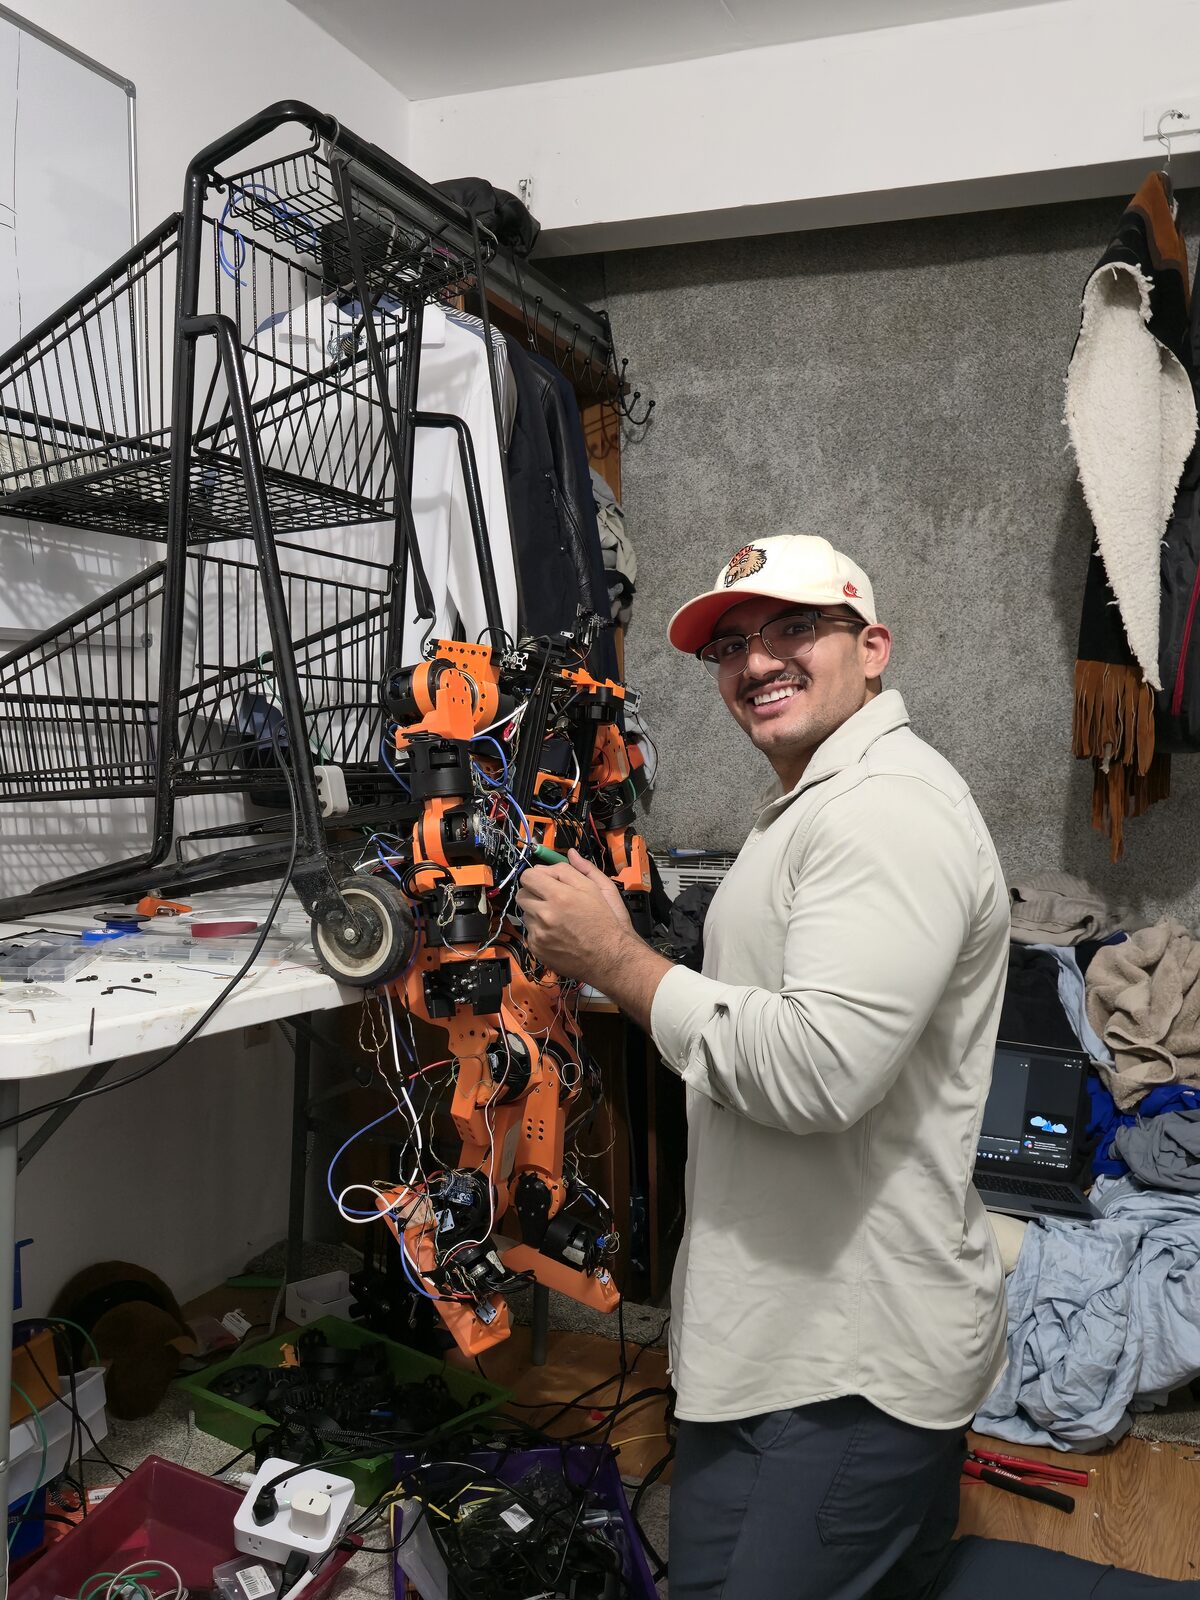
9 Sep — Resoldering some disconnected motors. 8 Sep — Configuring the LiDAR and stereo to the robot. 8 Sep — Another view of the LiDAR. 7 Sep — Setting up the computer. 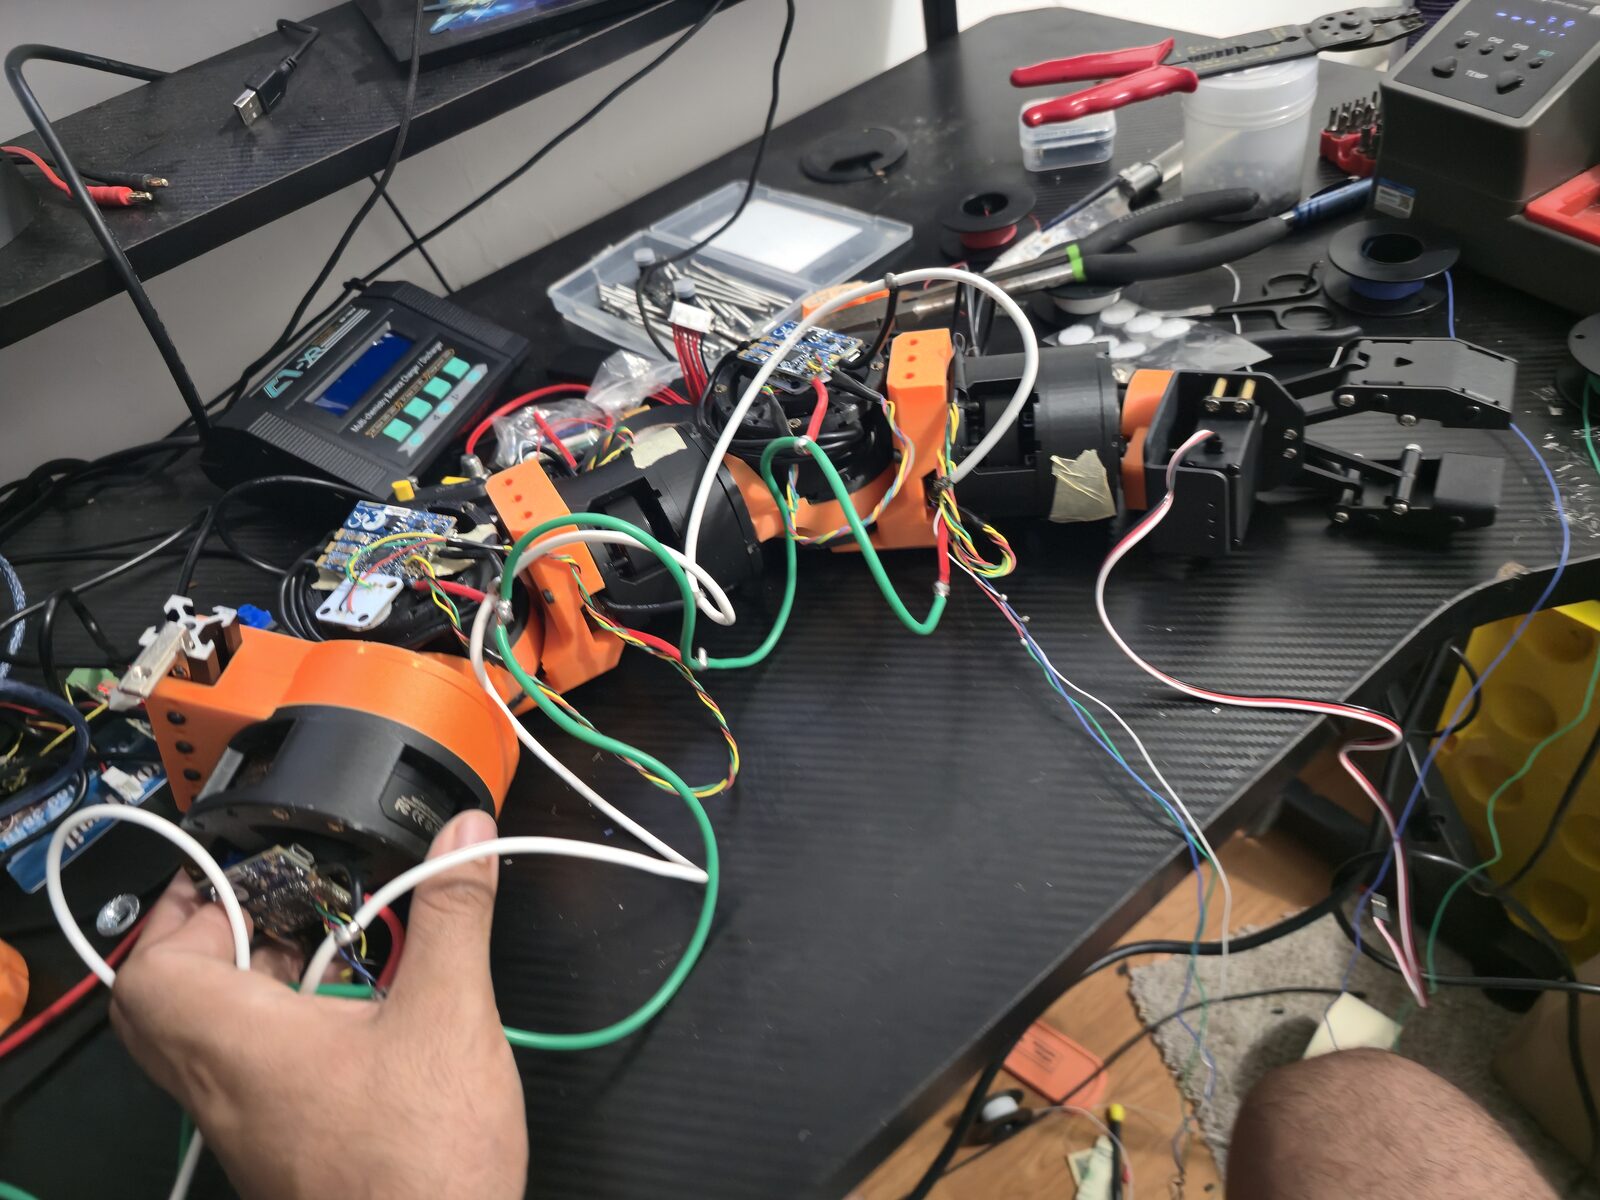
6 Sep — Getting cables nice. -
Humanoid: waiting on LiDAR and stereo
Back from Mexico on 26 Aug. Current stack is Beelink → Nano → BNO085. An IM10A IMU is due 25 Sep.
Legs stood on 3 Sep. Latest: upper stack is off the frame for the hip stopper and IMU. Perception hardware is still inbound: RPLIDAR C1, a 7” screen, and an MMlove synchronized global-shutter stereo camera — dual frames in one output, 3200×1200 at 60 fps or lower resolution at 120 fps, about 80 mm wide and 86 g. IFWATER is the other synchronized global-shutter option if that board slips.
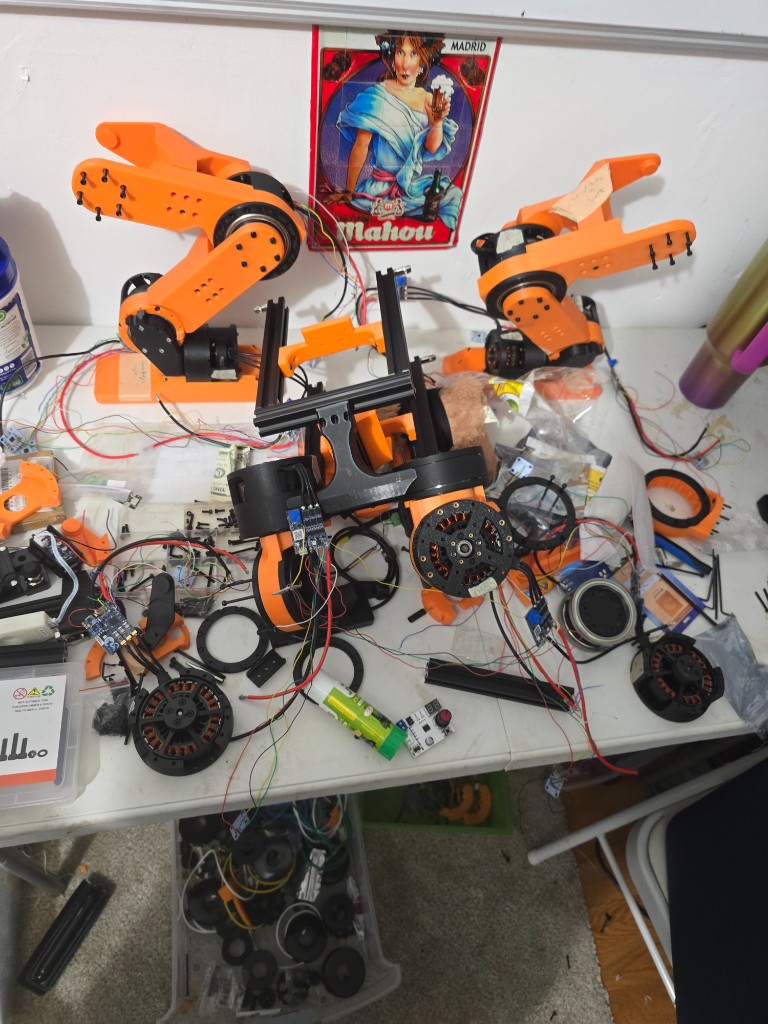
5 Sep — Dismantling the upper stack. Hip stopper and IMU mount exist in CAD only, not the official docs. Waiting on bolts. 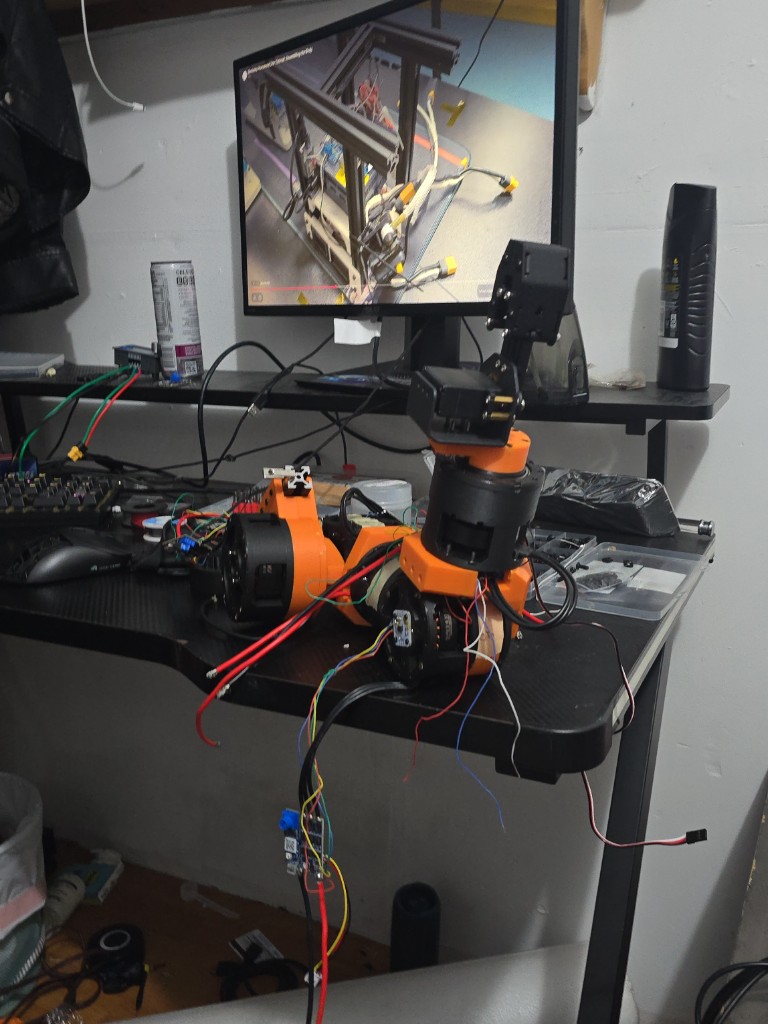
4 Sep — Arm beside the mini PC. Hands and compute mounting next. 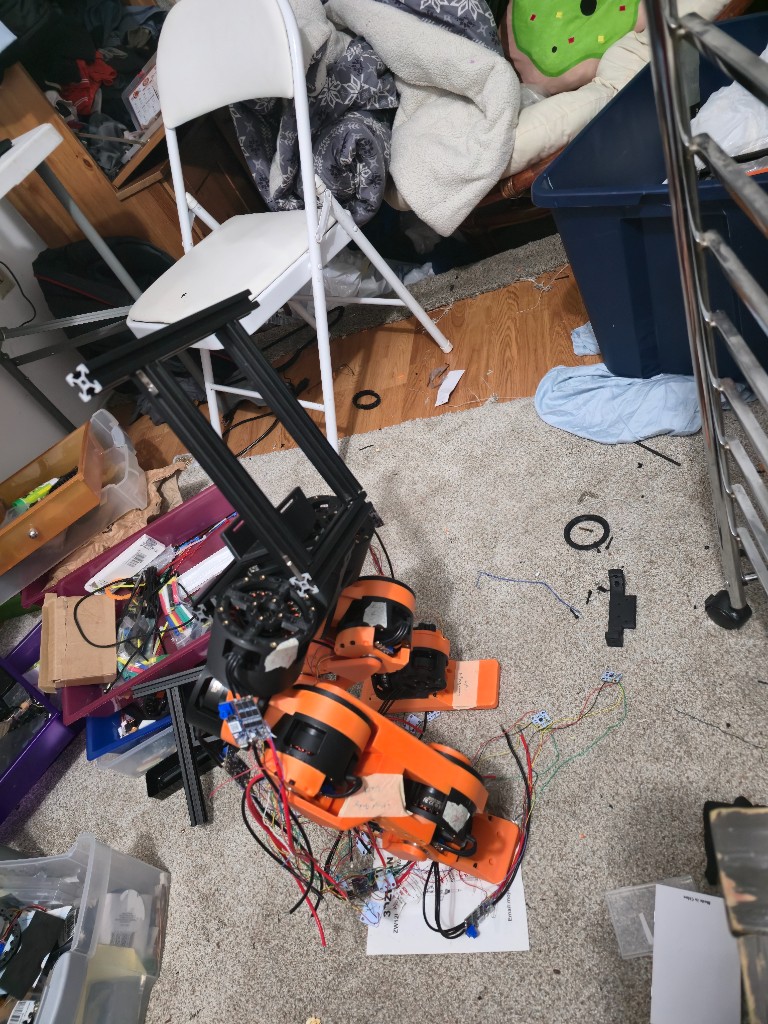
3 Sep — Legs standing, other side. Controllers still zip-tied to the limbs. 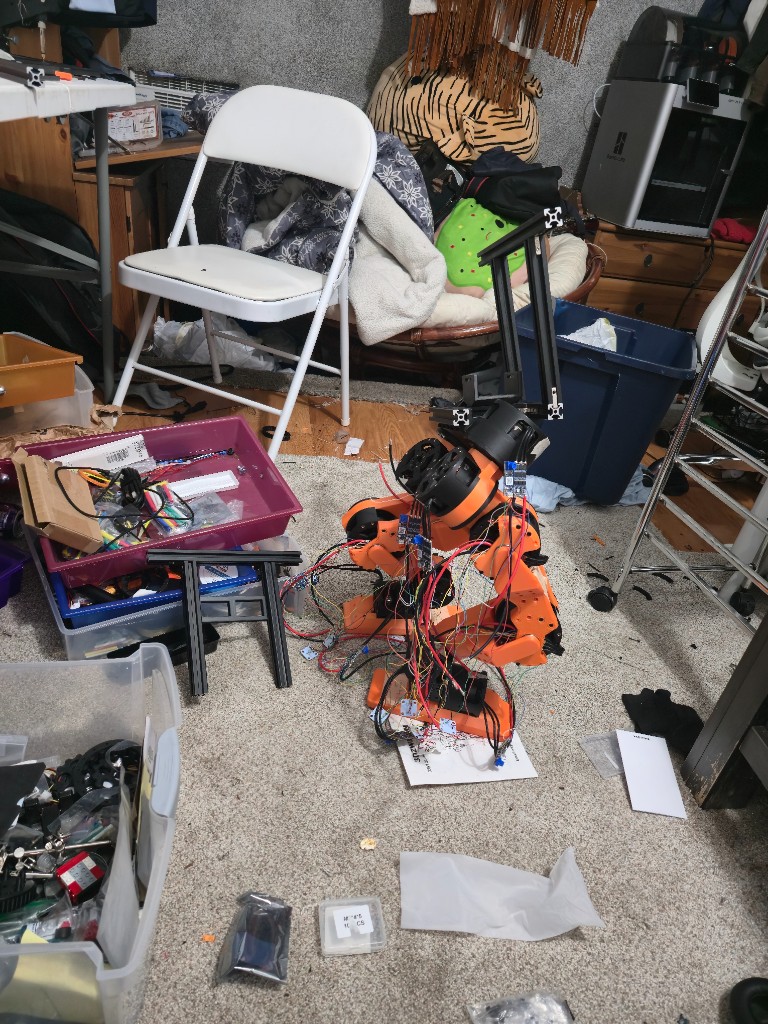
3 Sep — Legs standing on the hip extrusion. Lower body is mechanically together. 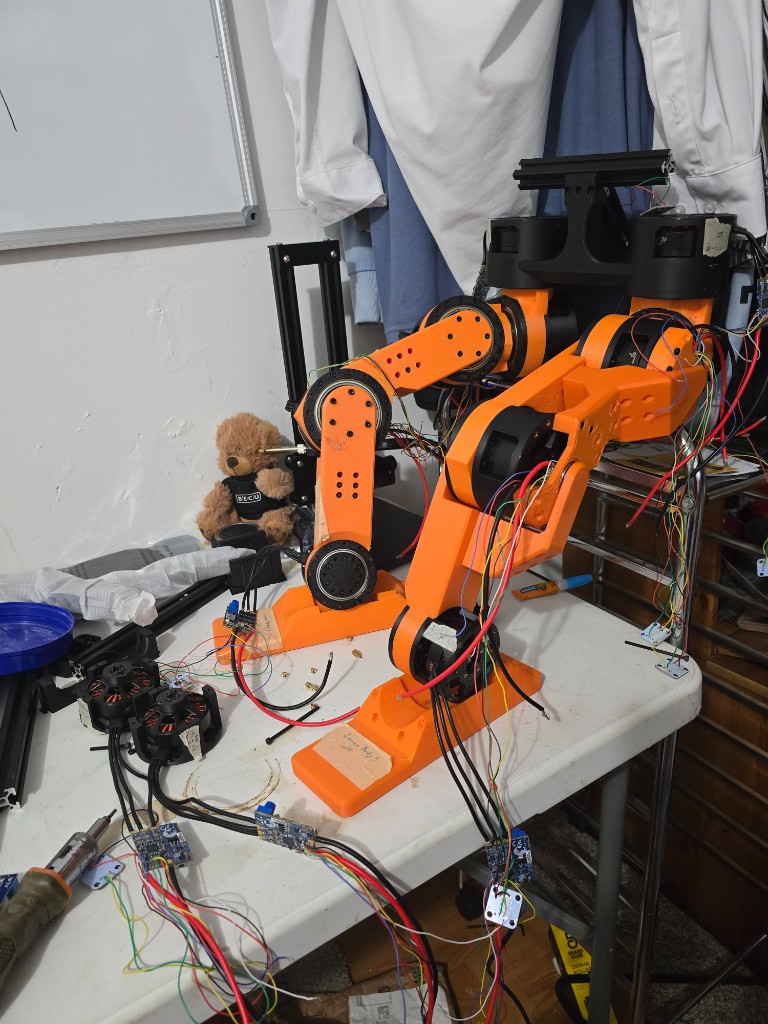
2 Sep — Both legs assembled. Wiring harness still external; ankles next. 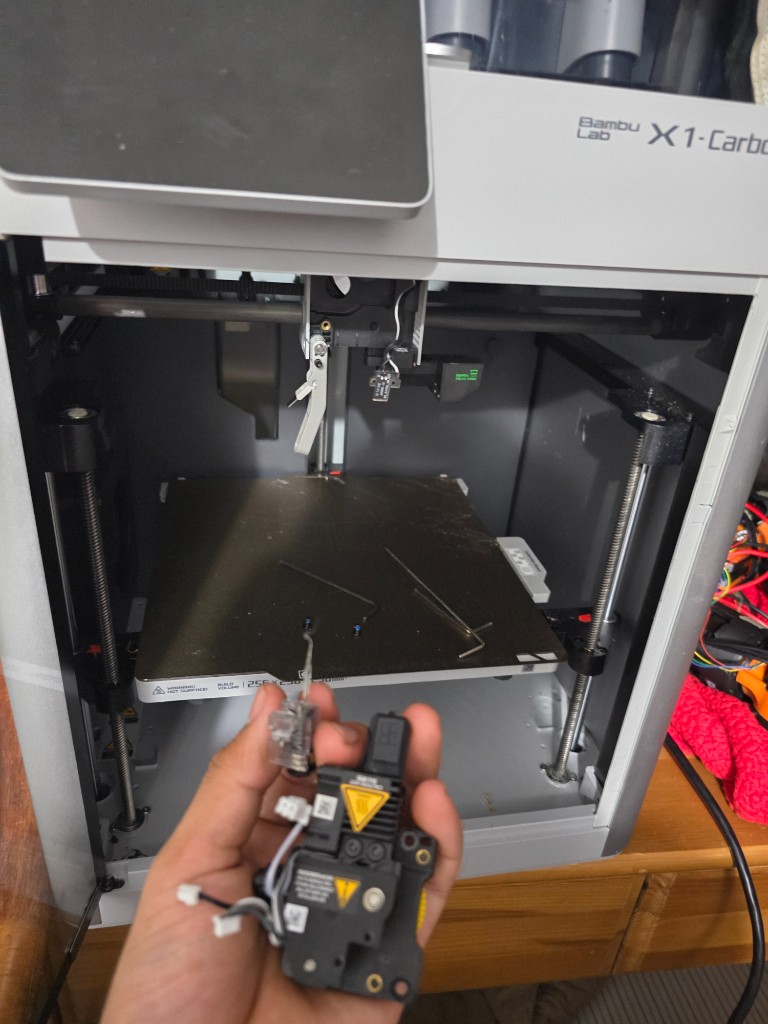
1 Sep — X1-Carbon hotend out so I could reprint ankle parts. 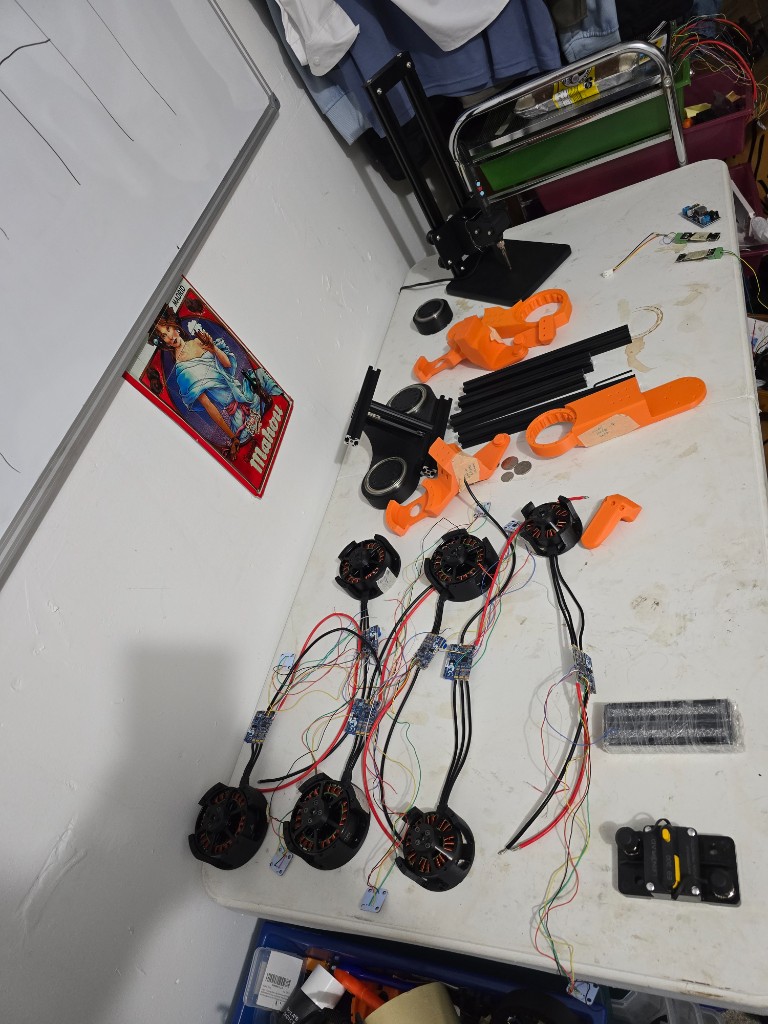
29 Aug — Left-leg motors calibrated. Six actuators still on the bench, ESC boards off-chassis. -
Building the Berkeley Humanoid Lite
Assembling the open-source Berkeley Humanoid Lite: mechanical assembly, soldering, and CAD modeling, with ROS2 and Isaac Sim integration for motion control and reinforcement learning. Currently mid-build — updates here as joints start moving.
-
This site
Built this site: Astro content collections with Zod-enforced brevity, a numbered figure system, a scroll-progress ruler, and a liquid blue/red cursor. Next: swapping placeholder figures for real project media.