Open source robotics
Building an open-source humanoid from scratch — self-funded, in a garage — to get first-hand experience across the whole stack, from soldering to reinforcement learning in NVIDIA Isaac Sim.
-
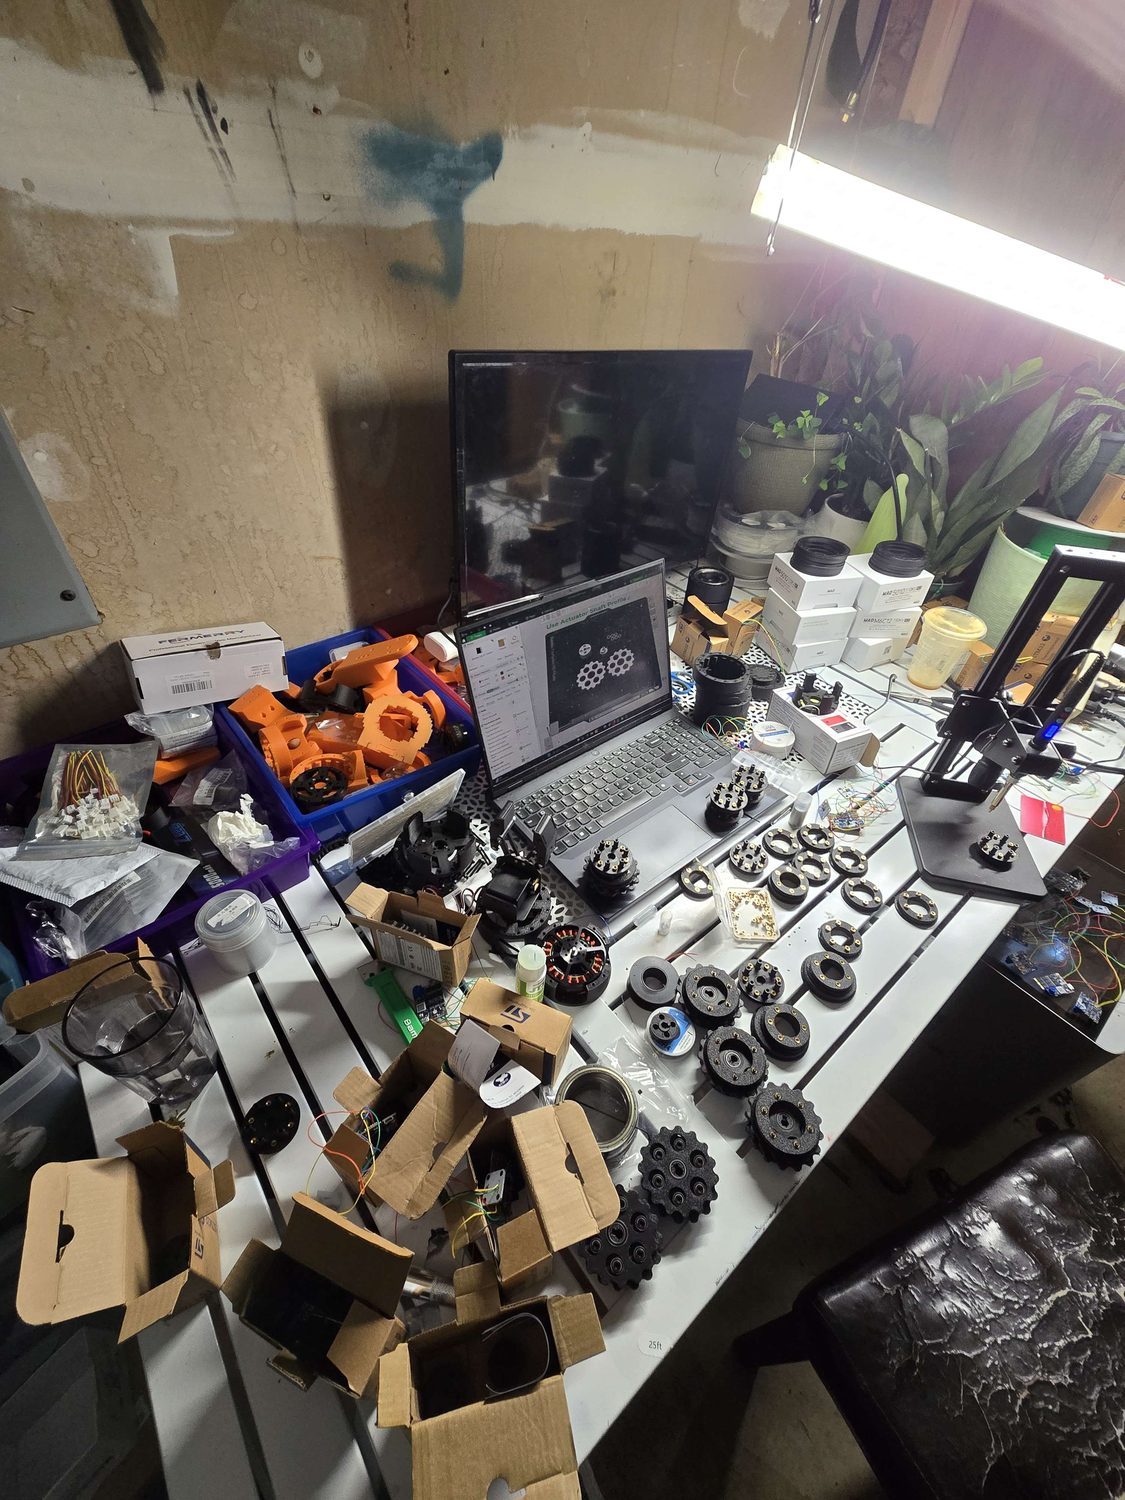
01 Bench set up — printer in, parts staged, actuator profiles on screen. -
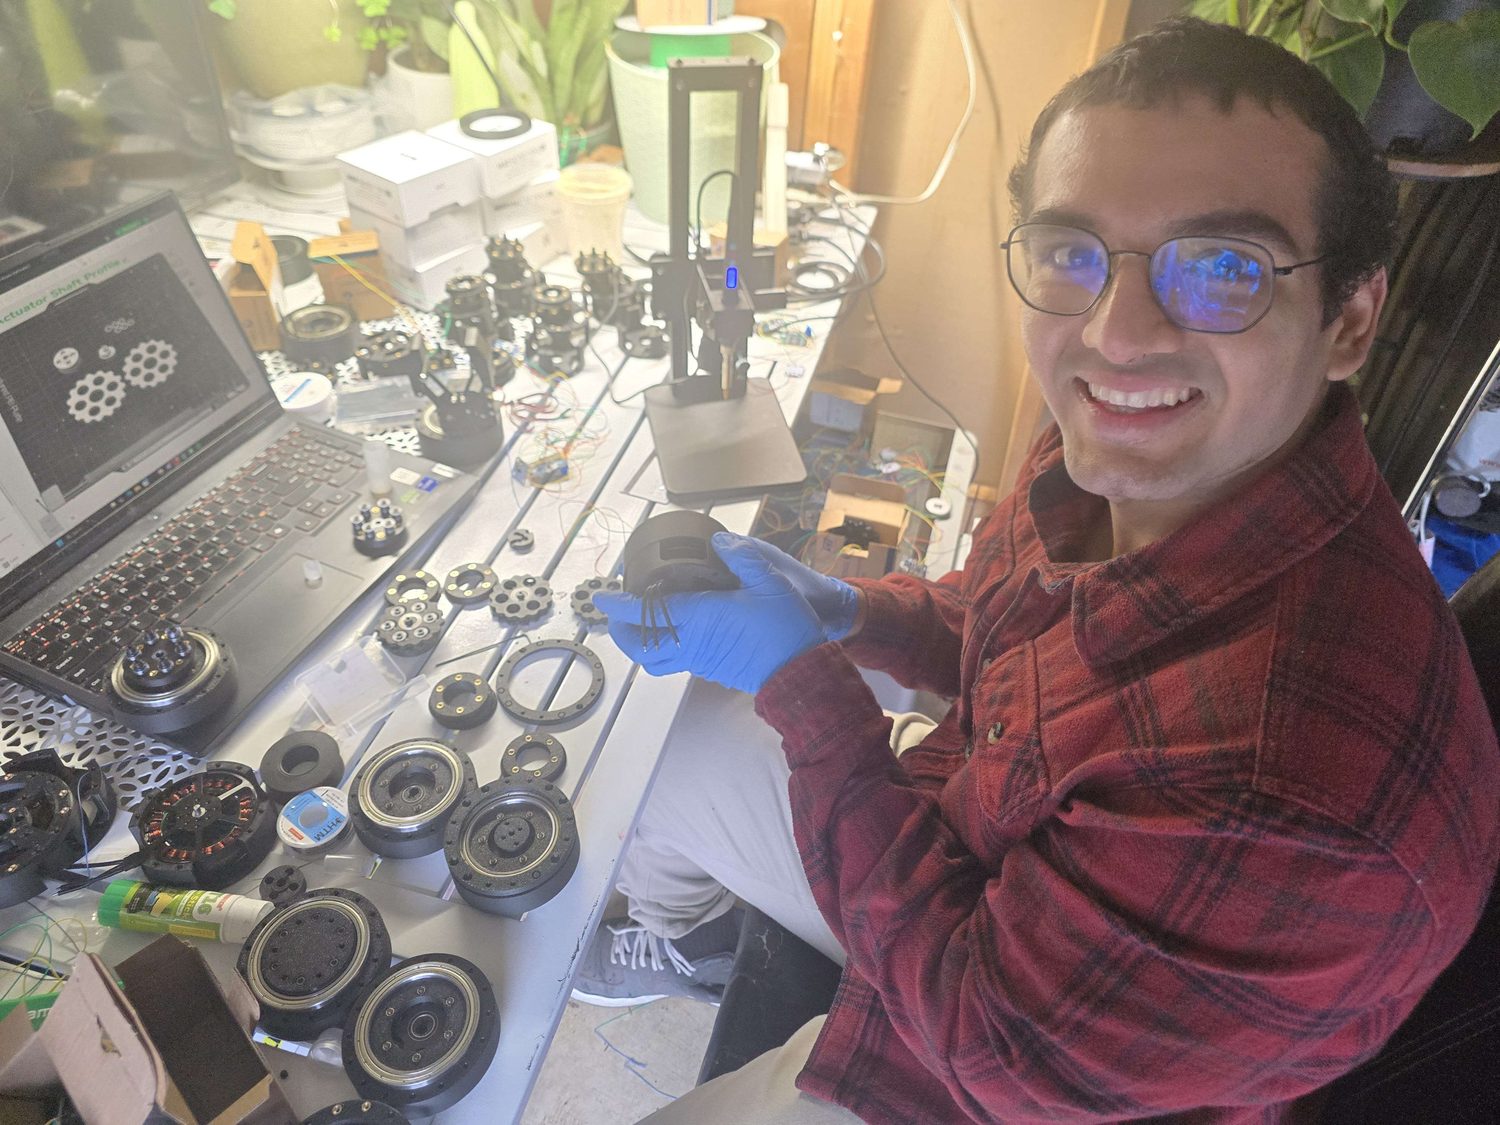
02 Building the actuators — rotors, bearings and housings. -
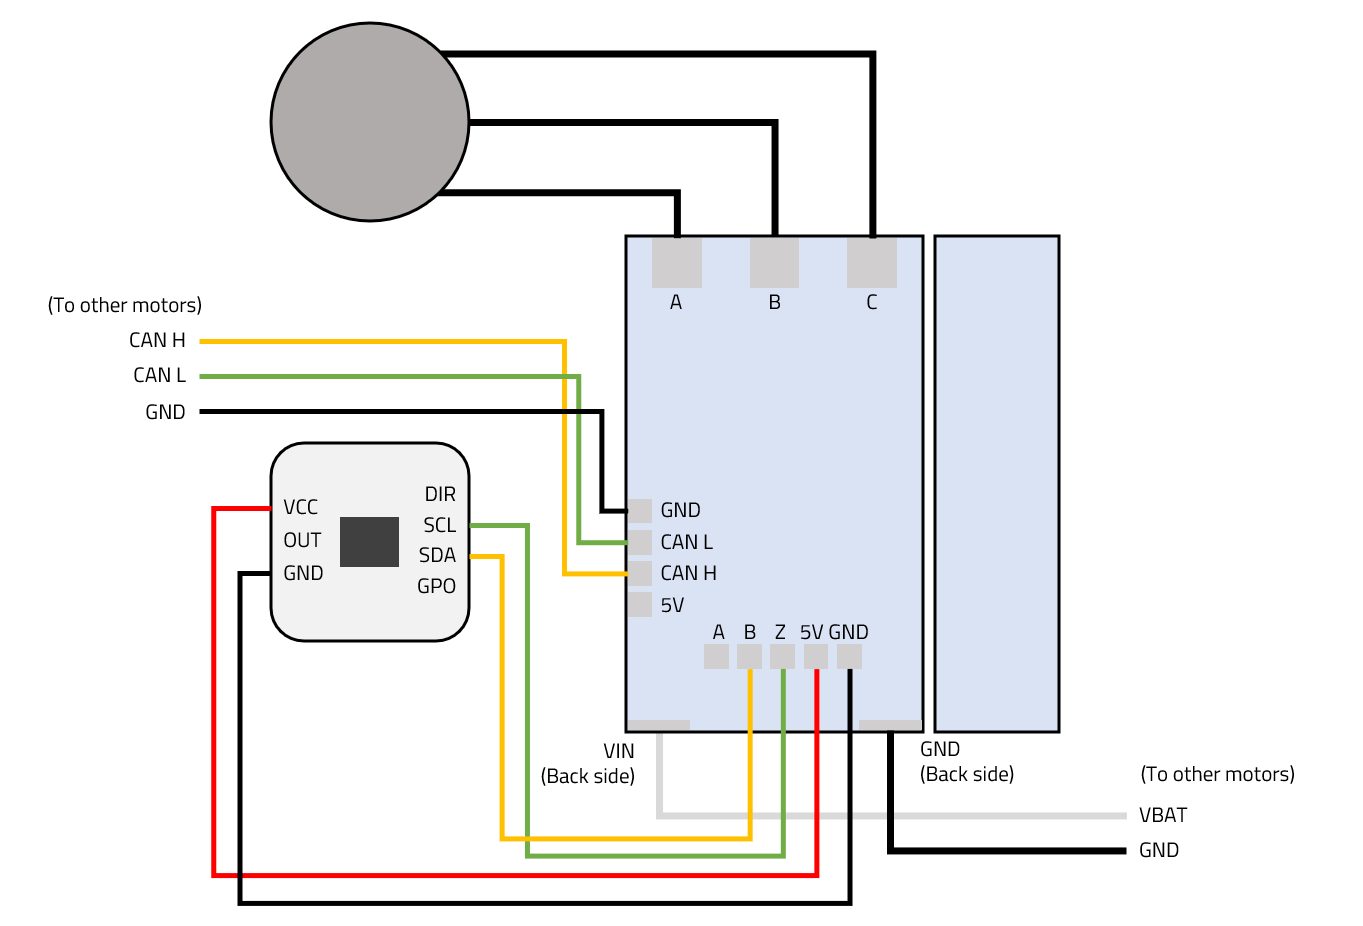
03 One joint's wiring: AS5600 encoder to B-G431B-ESC1, CAN chained onward. -
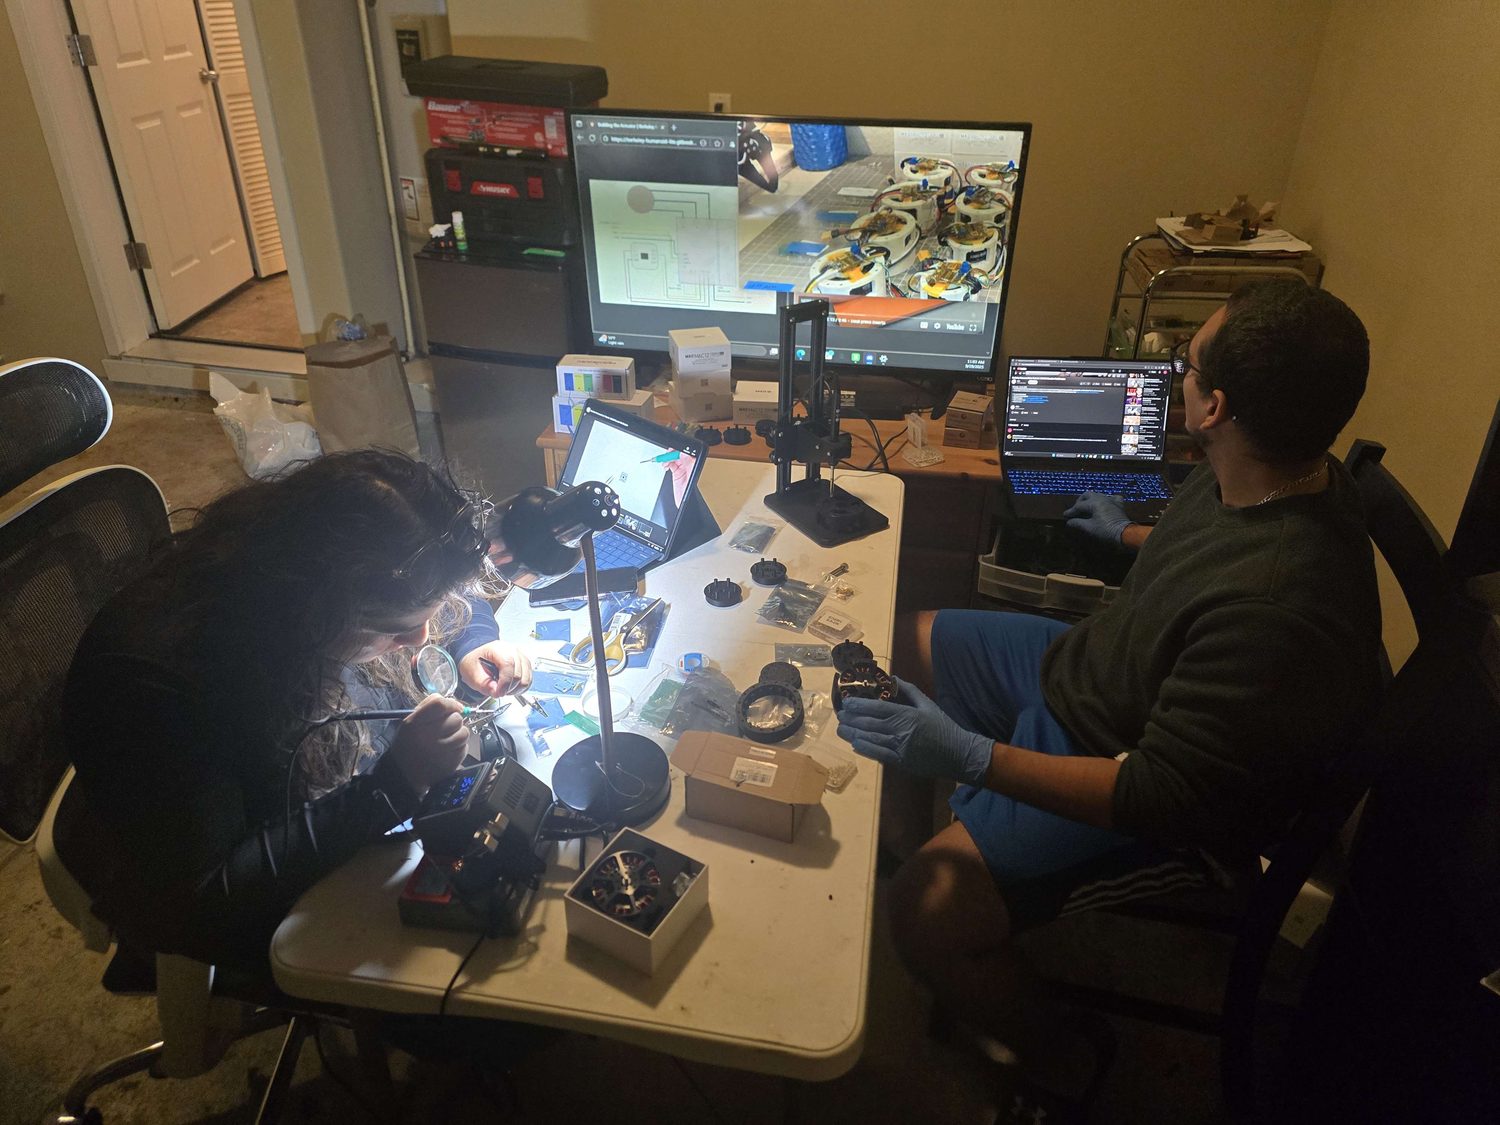
04 22 encoders to solder, so my sister took a shift. -
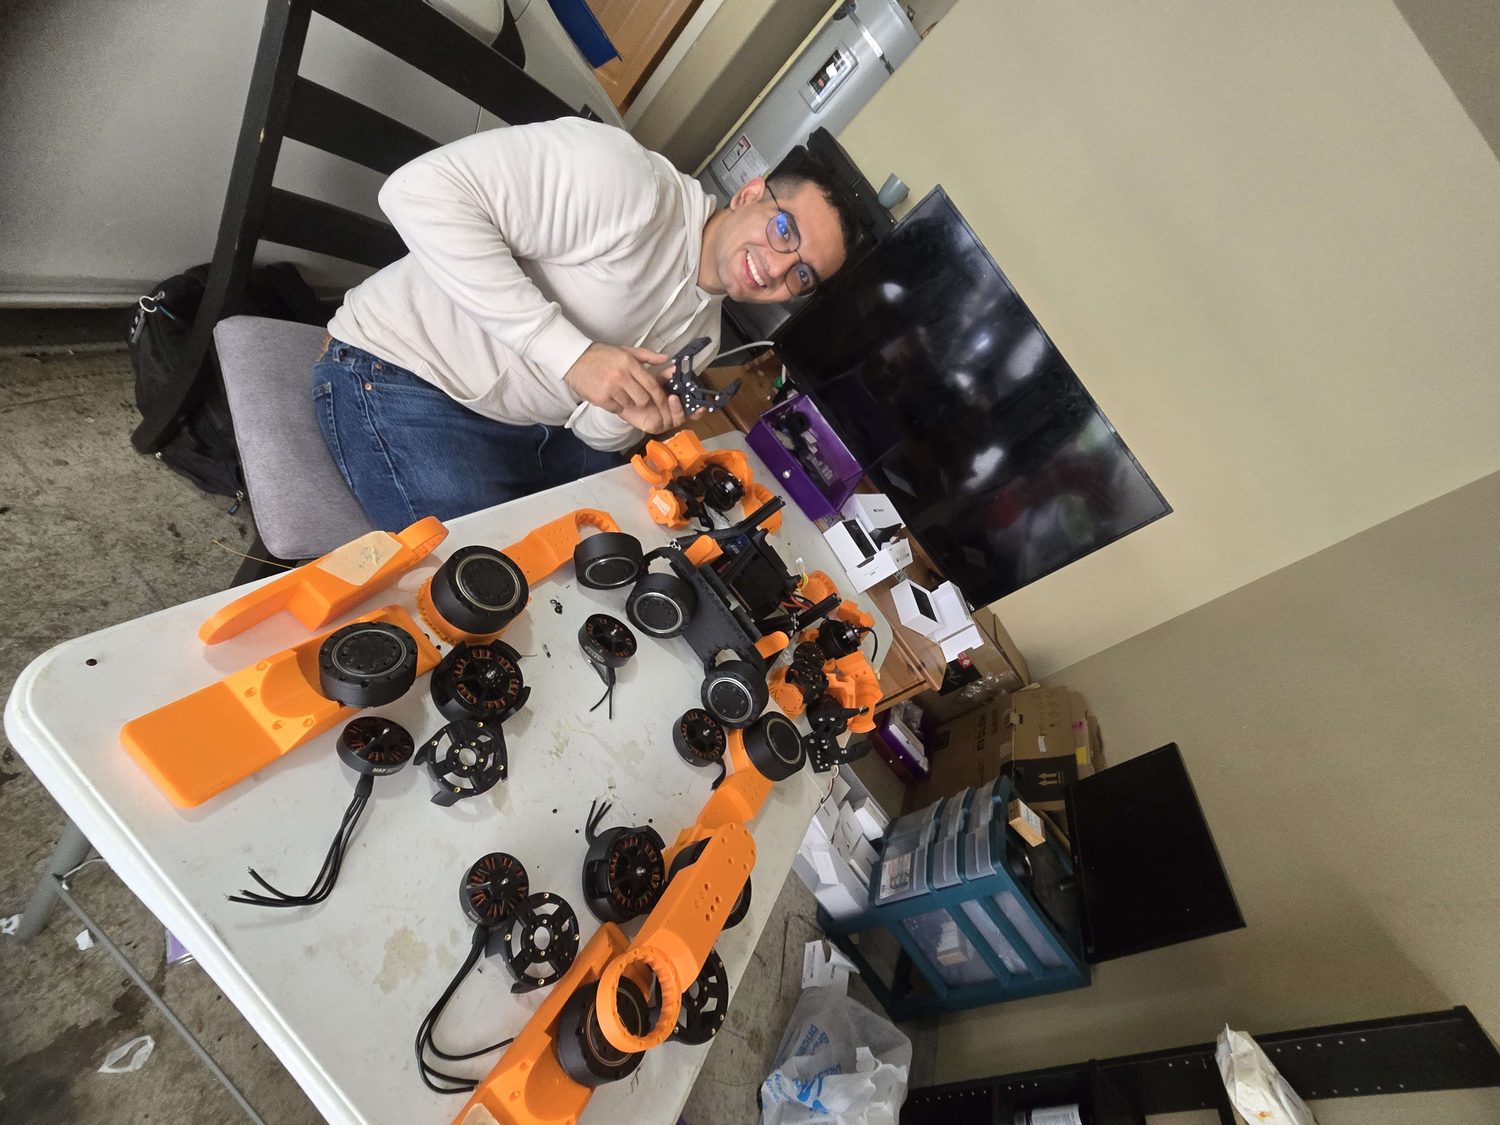
05 Every structural part, printed and sorted. -
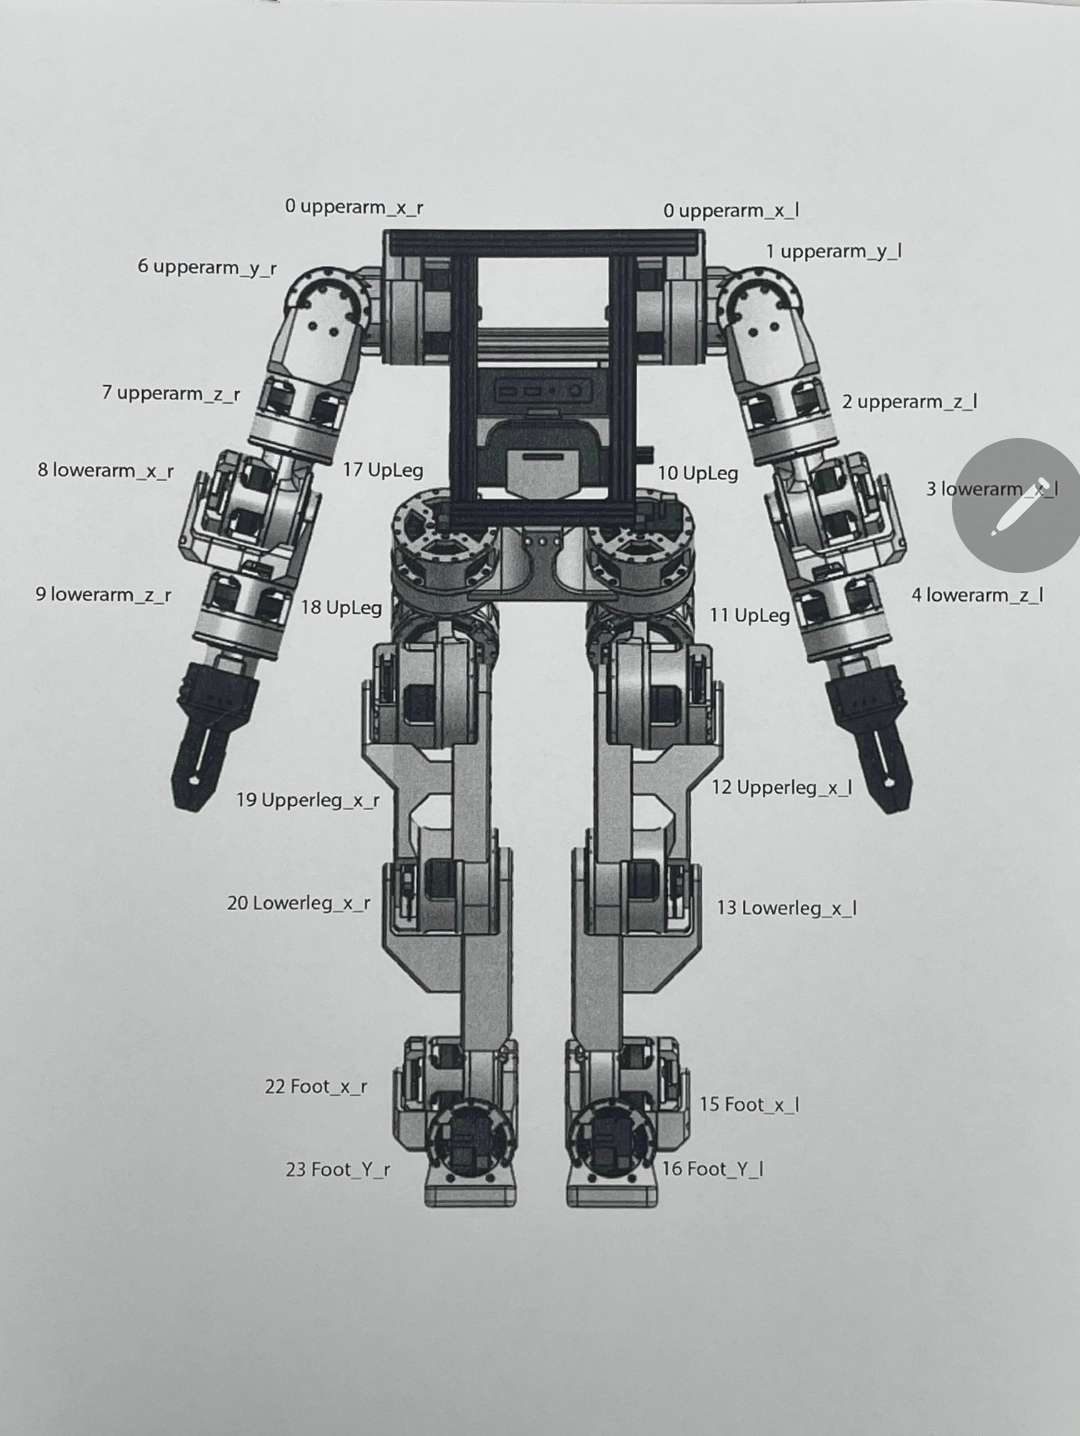
06 The CAD render the build works from. -
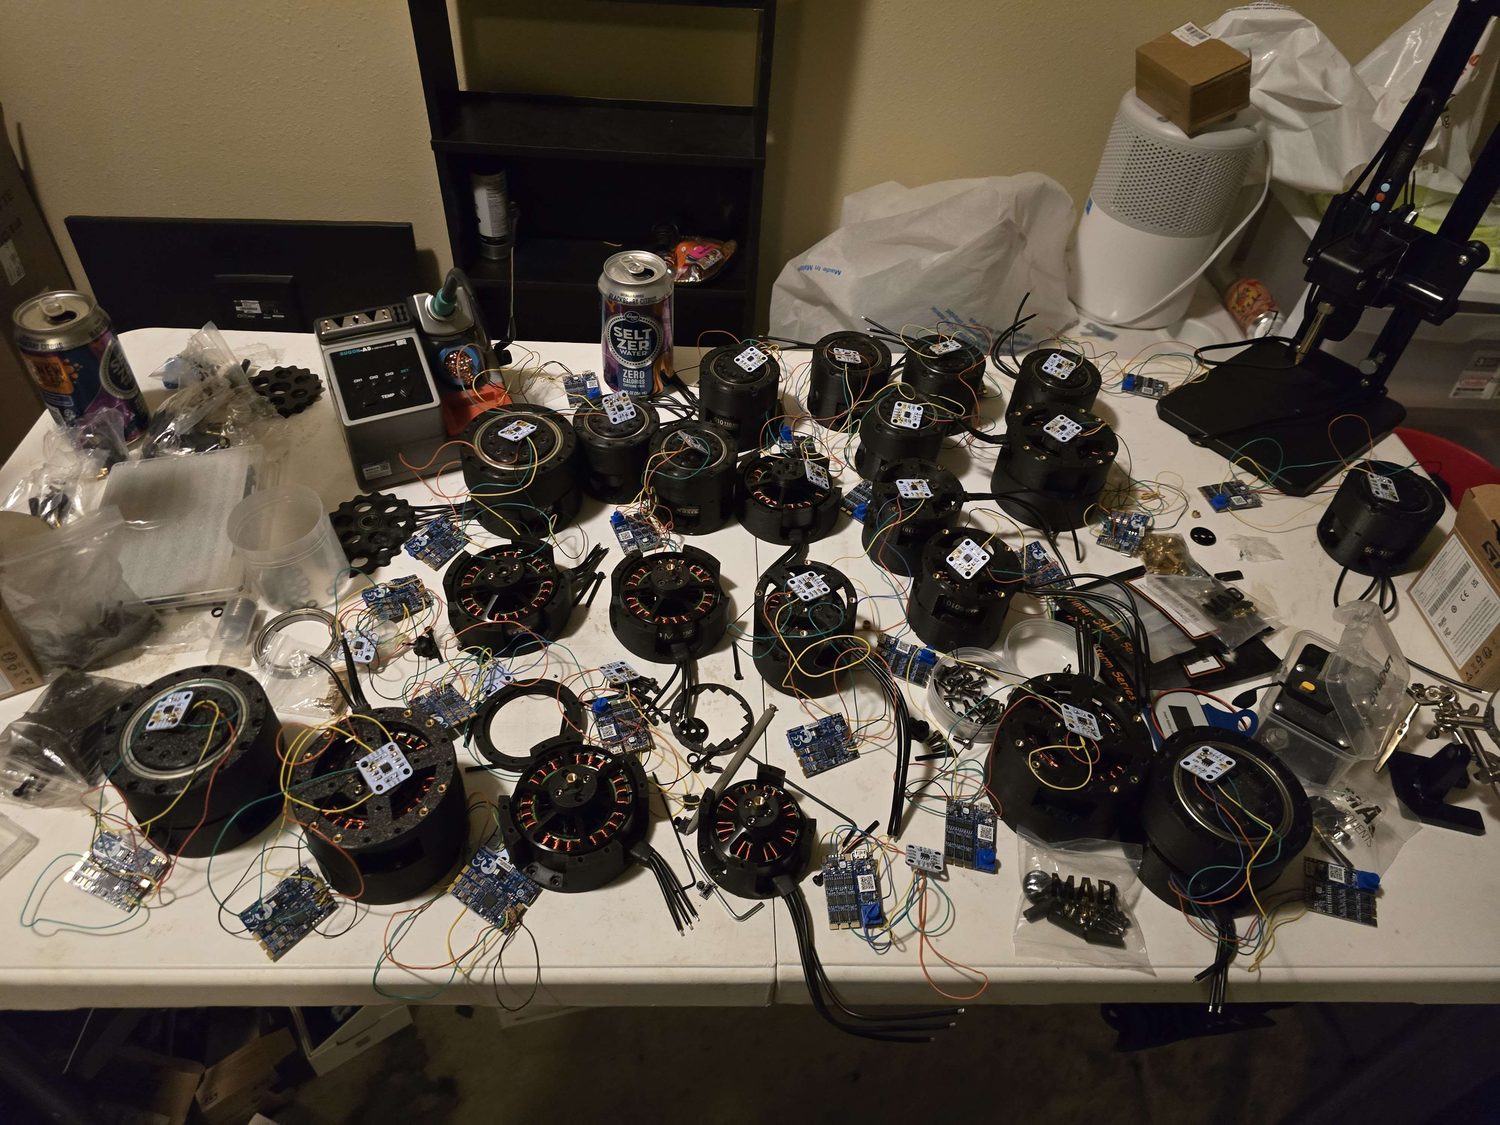
07 All 22 actuators and controllers soldered. -
08 Calibrating an MC612 actuator. -
09 Calibrating a 5010 actuator. -
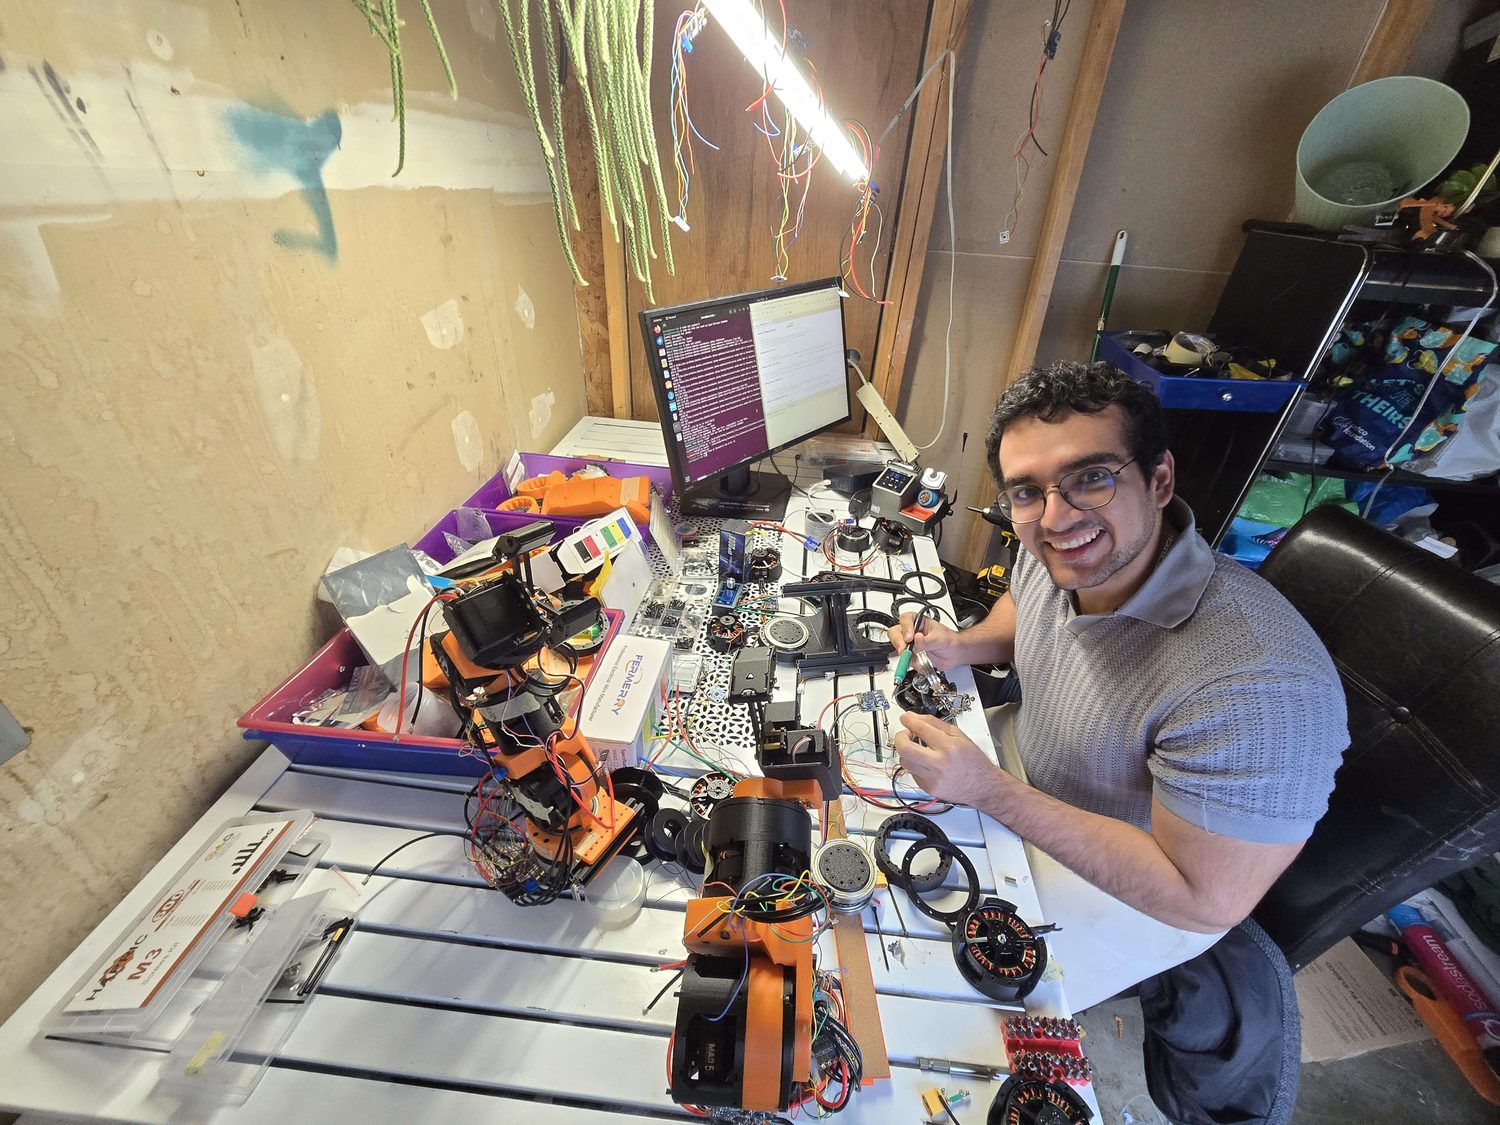
10 Arms mostly assembled — 12 motors in, 10 to go. -
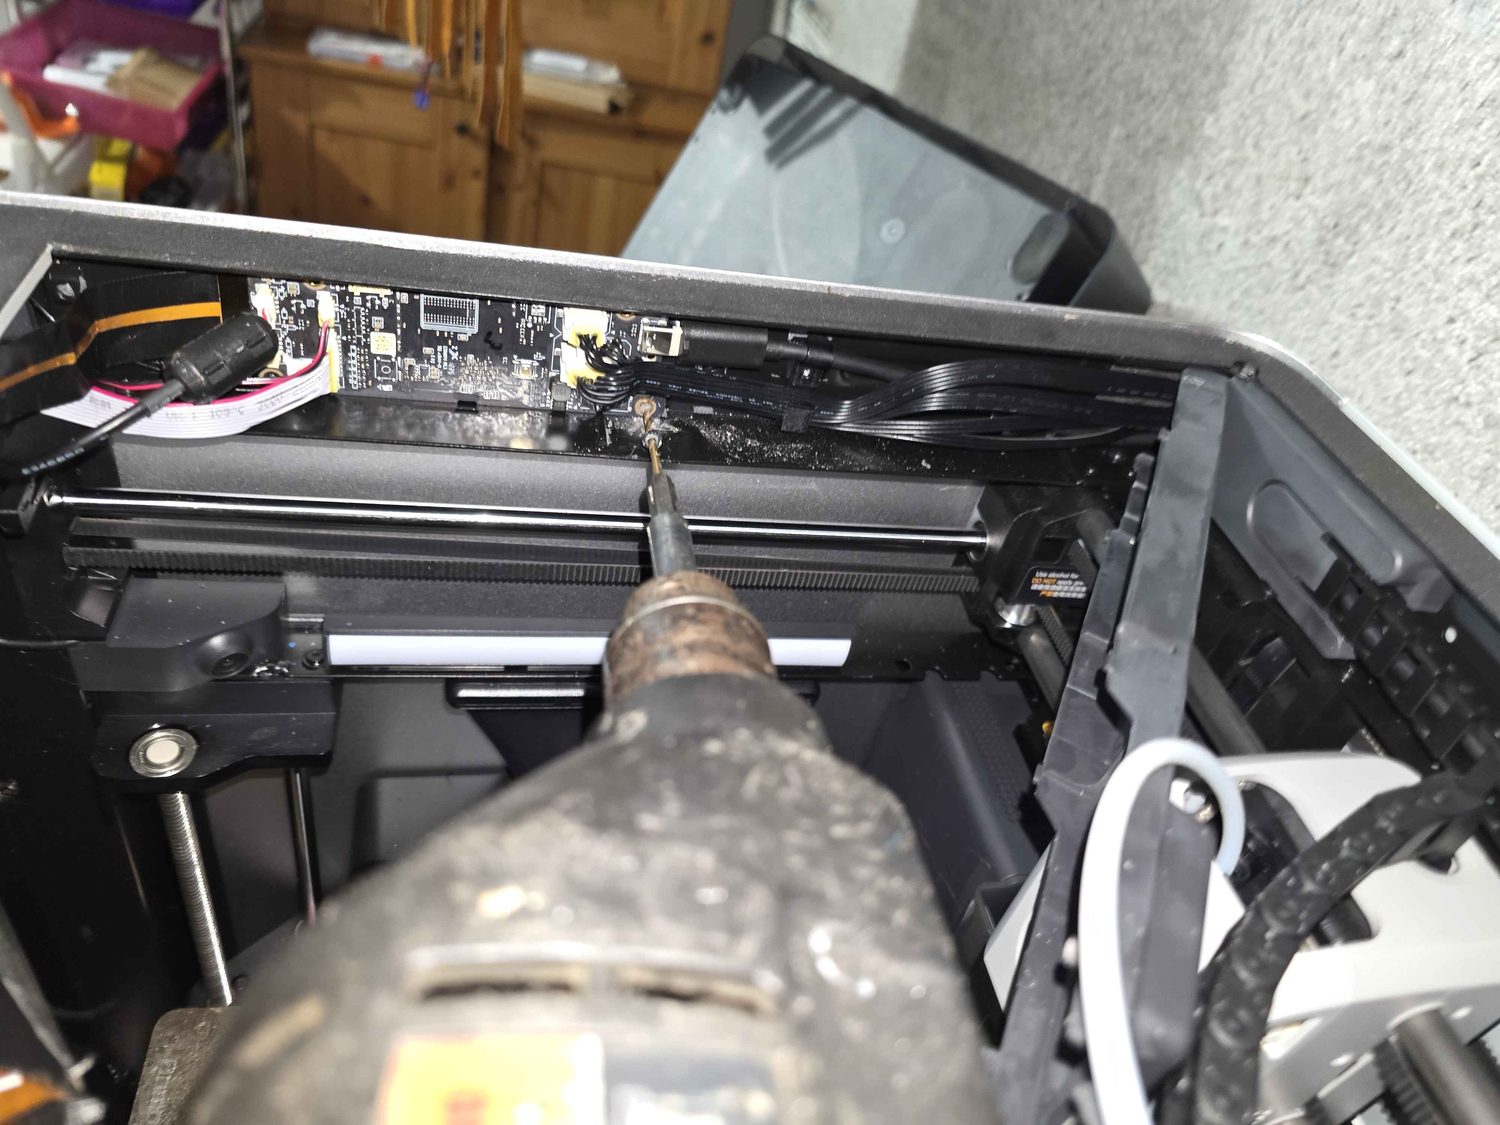
11 Broke the printer screen — opened it up to replace the screen and cable. -
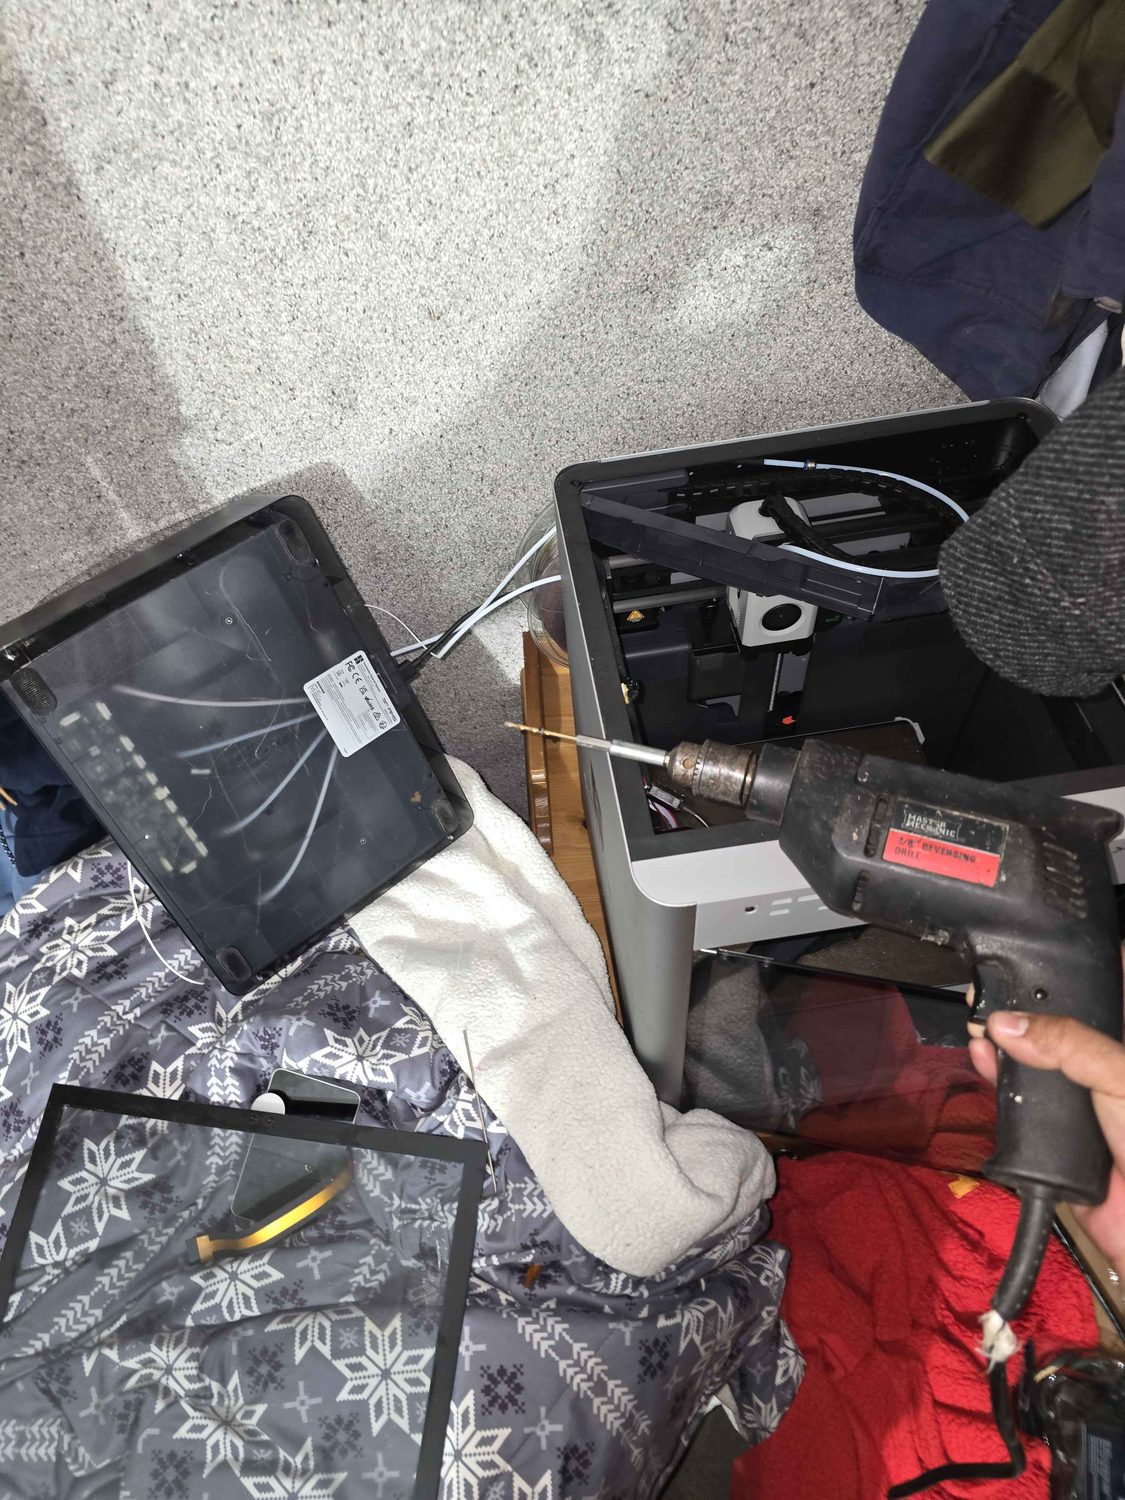
12 A stripped screw and one precise drill later: fixed. -
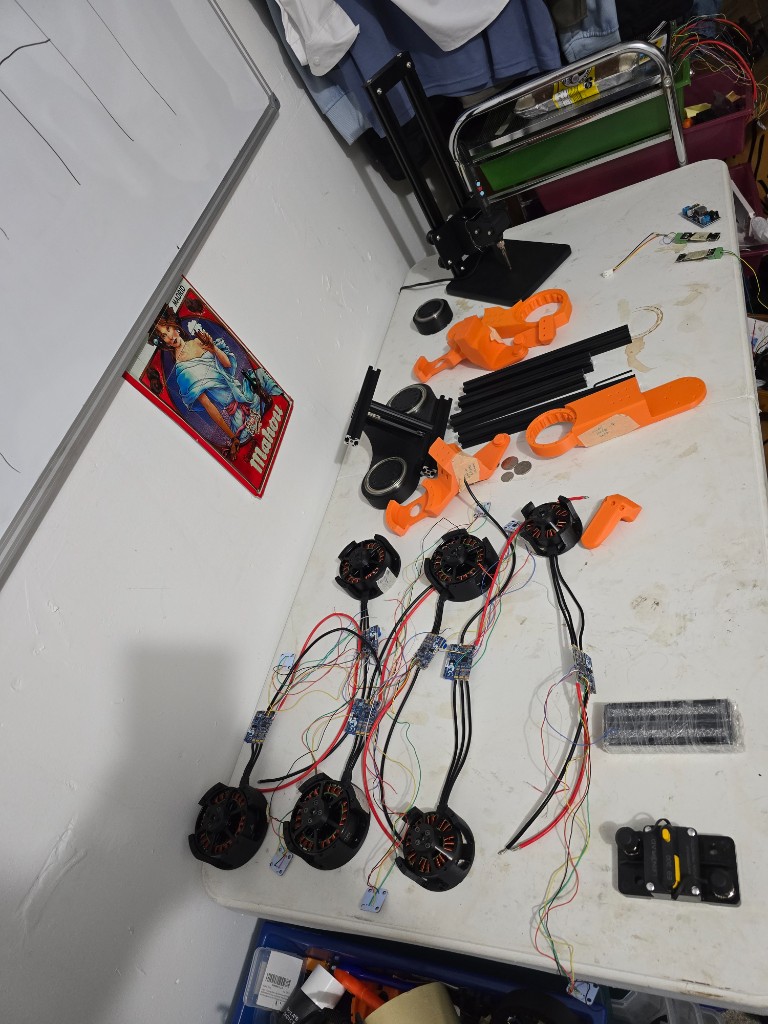
13 29 Aug — Left-leg motors calibrated; ESCs still off-chassis. -
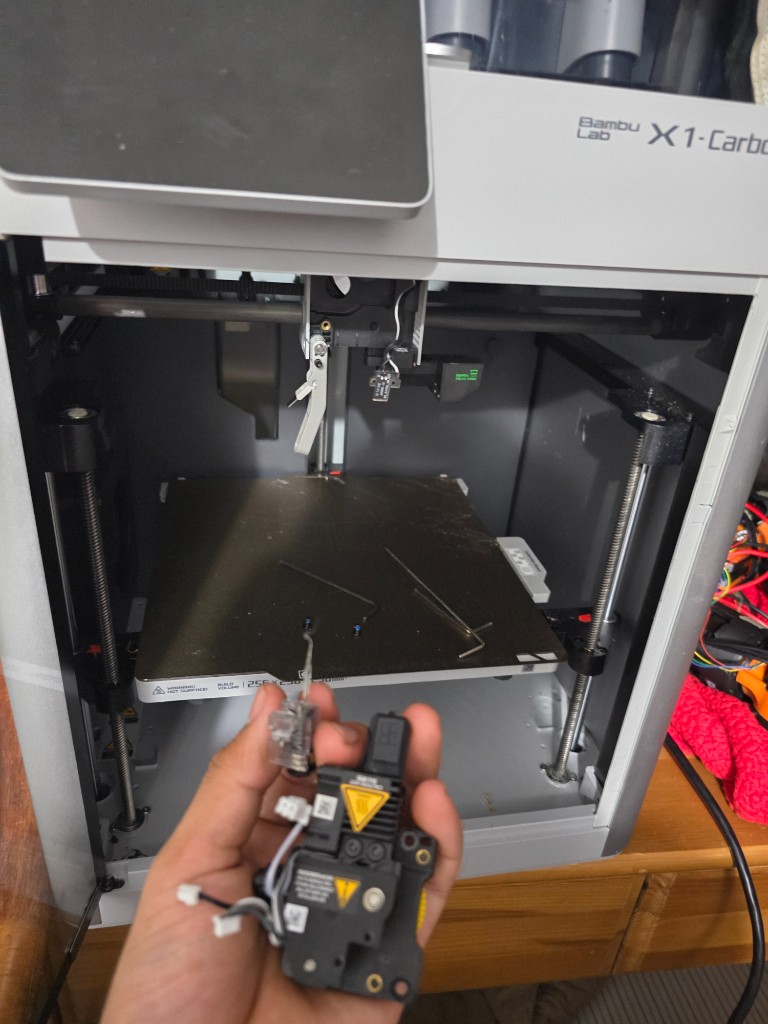
14 1 Sep — Hotend out to reprint ankle parts. -
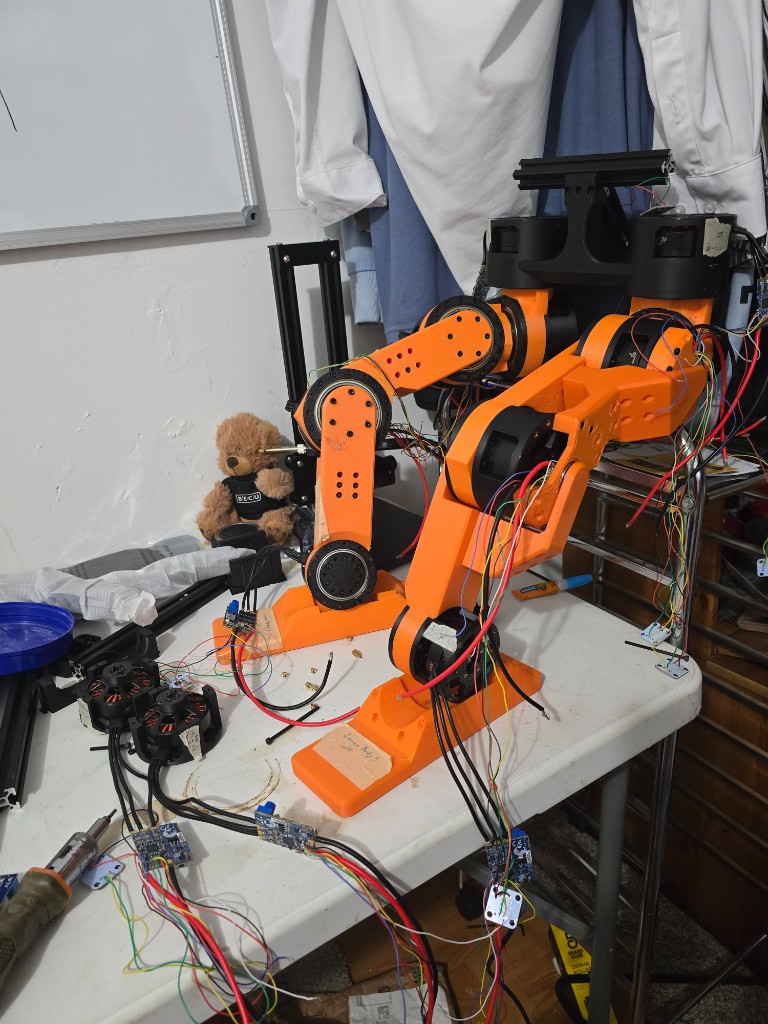
15 2 Sep — Legs assembled, ready to pin the ankles. -
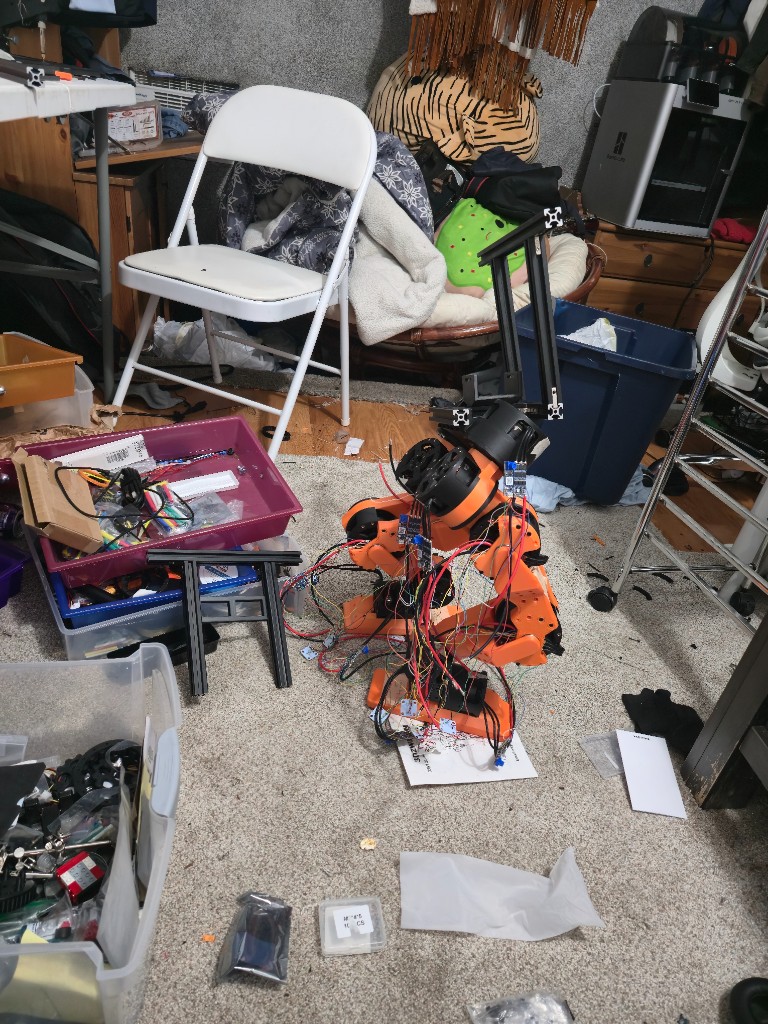
16 3 Sep — Legs standing on the hip extrusion. -
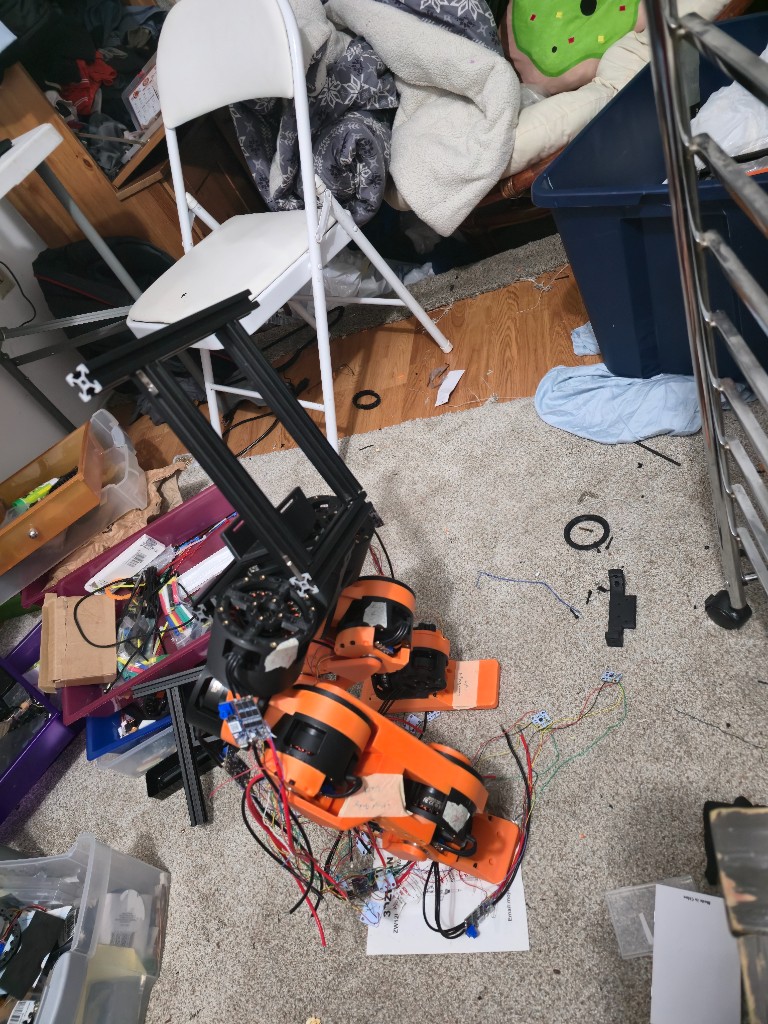
17 3 Sep — Standing assembly, other side. -
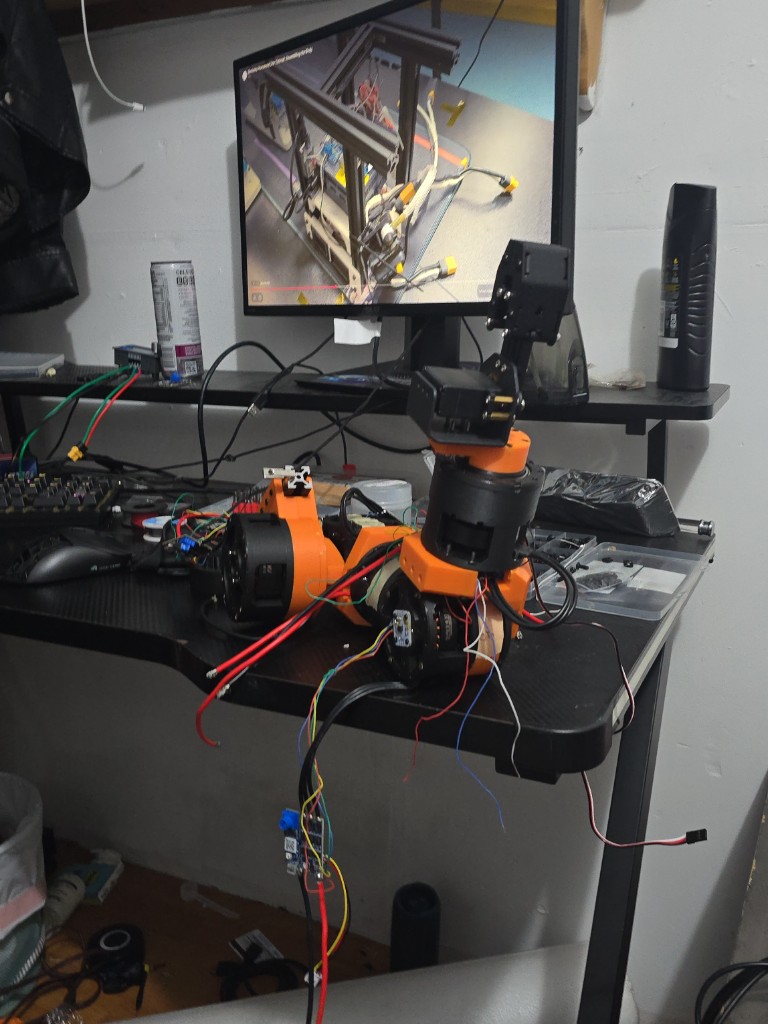
18 4 Sep — Arm beside the mini PC; hands and compute next. -
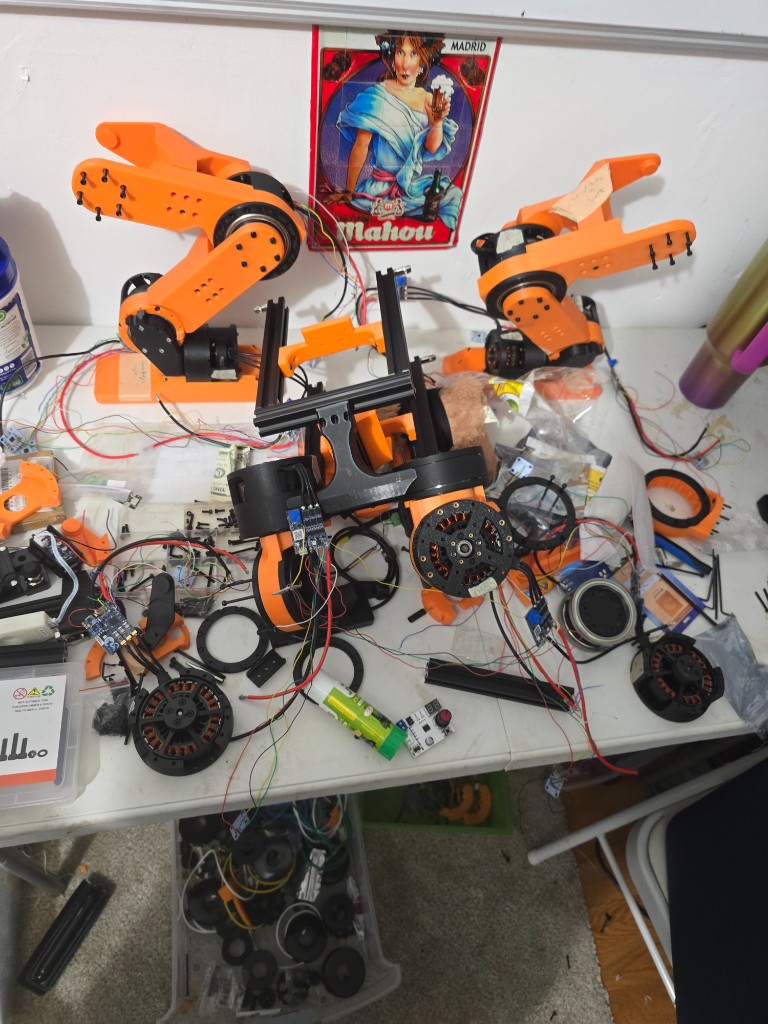
19 5 Sep — Dismantling the upper stack. Stopper and IMU mount are CAD-only; waiting on bolts. -
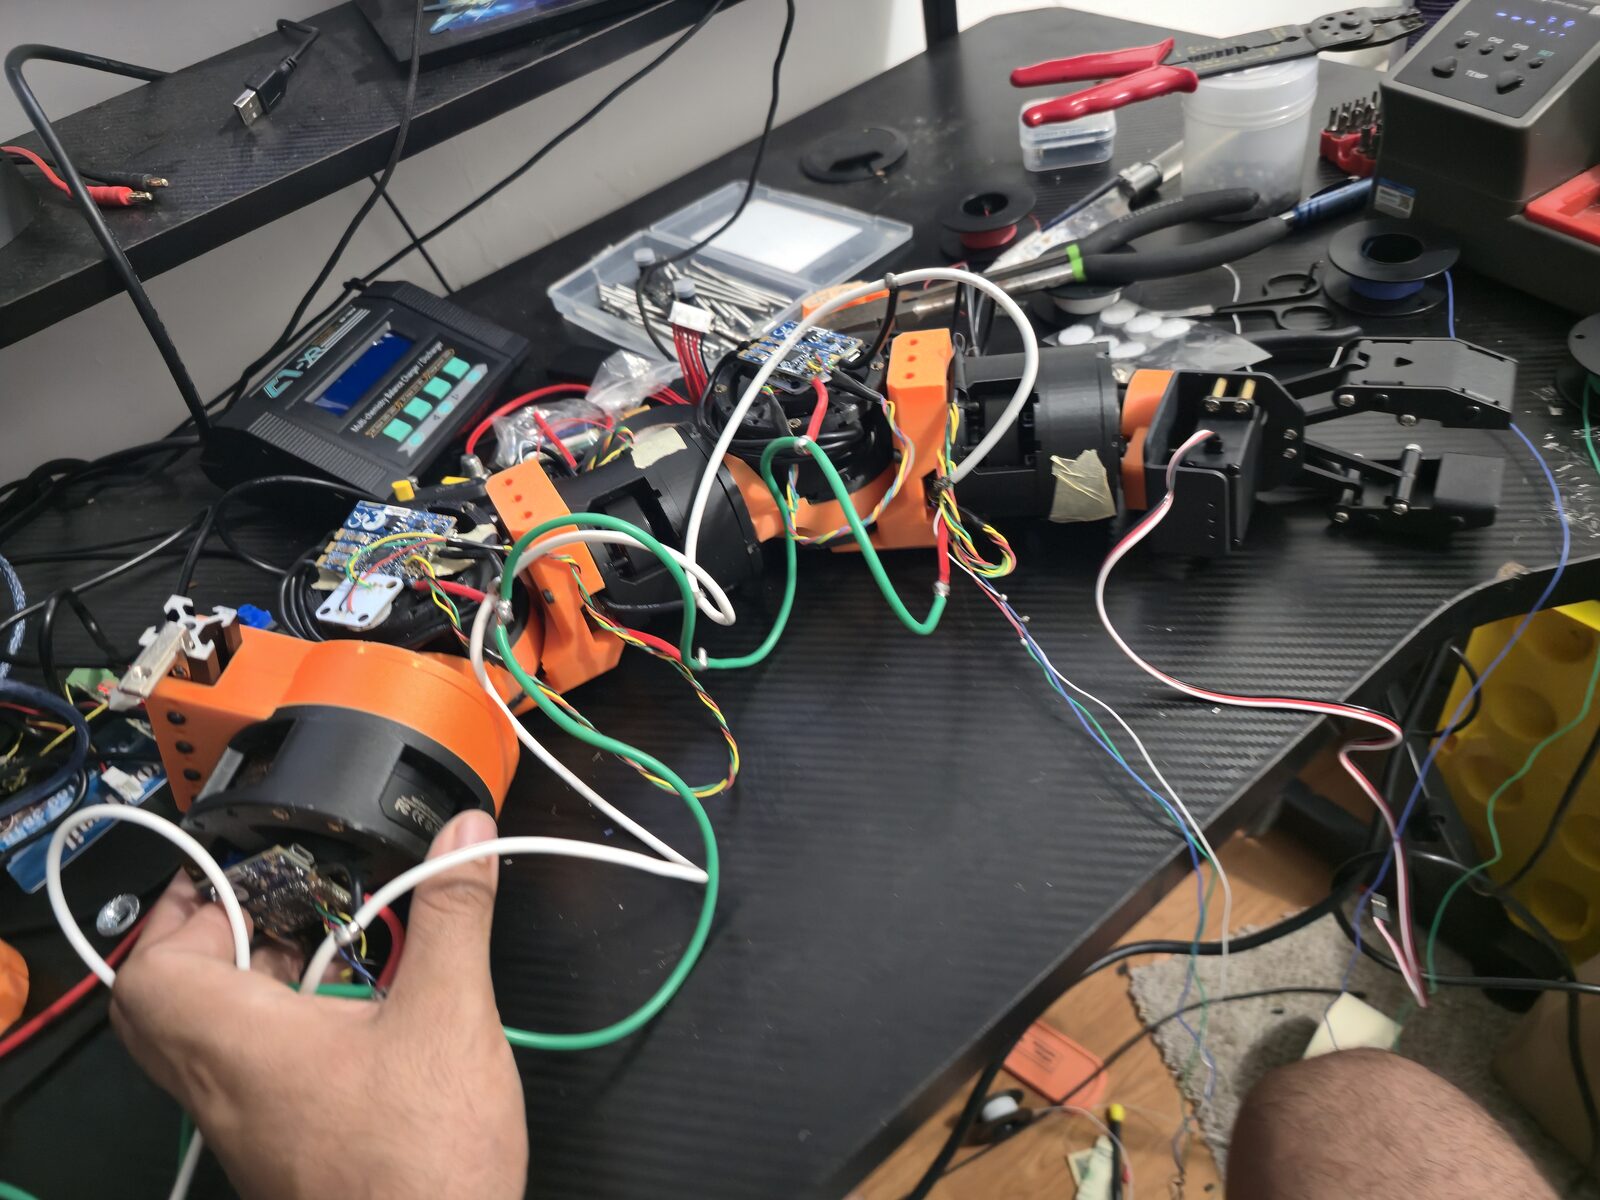
20 6 Sep — Getting cables nice. -
21 7 Sep — Setting up the computer. -
22 8 Sep — Configuring the LiDAR and stereo to the robot. -
23 8 Sep — Another view of the LiDAR. -
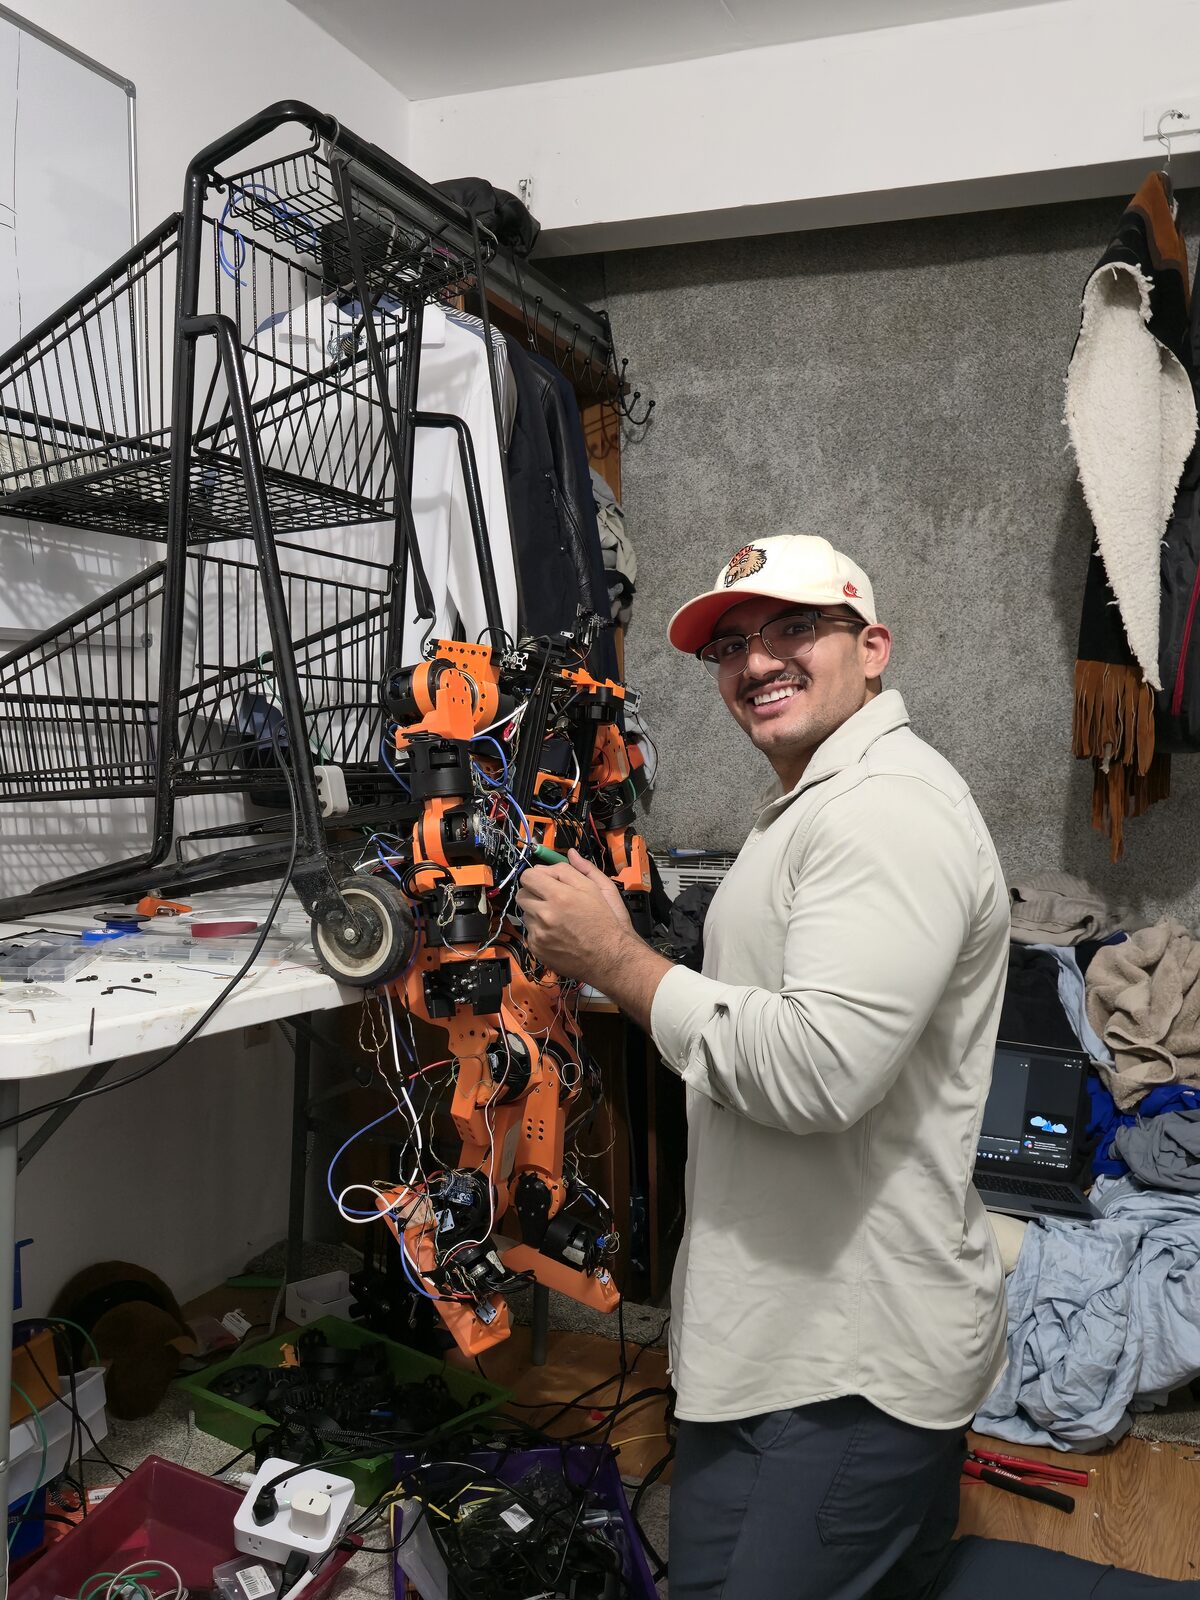
24 9 Sep — Resoldering some disconnected motors. -
25 10 Sep — Running diagnostic on onboard computer to configure motors. -
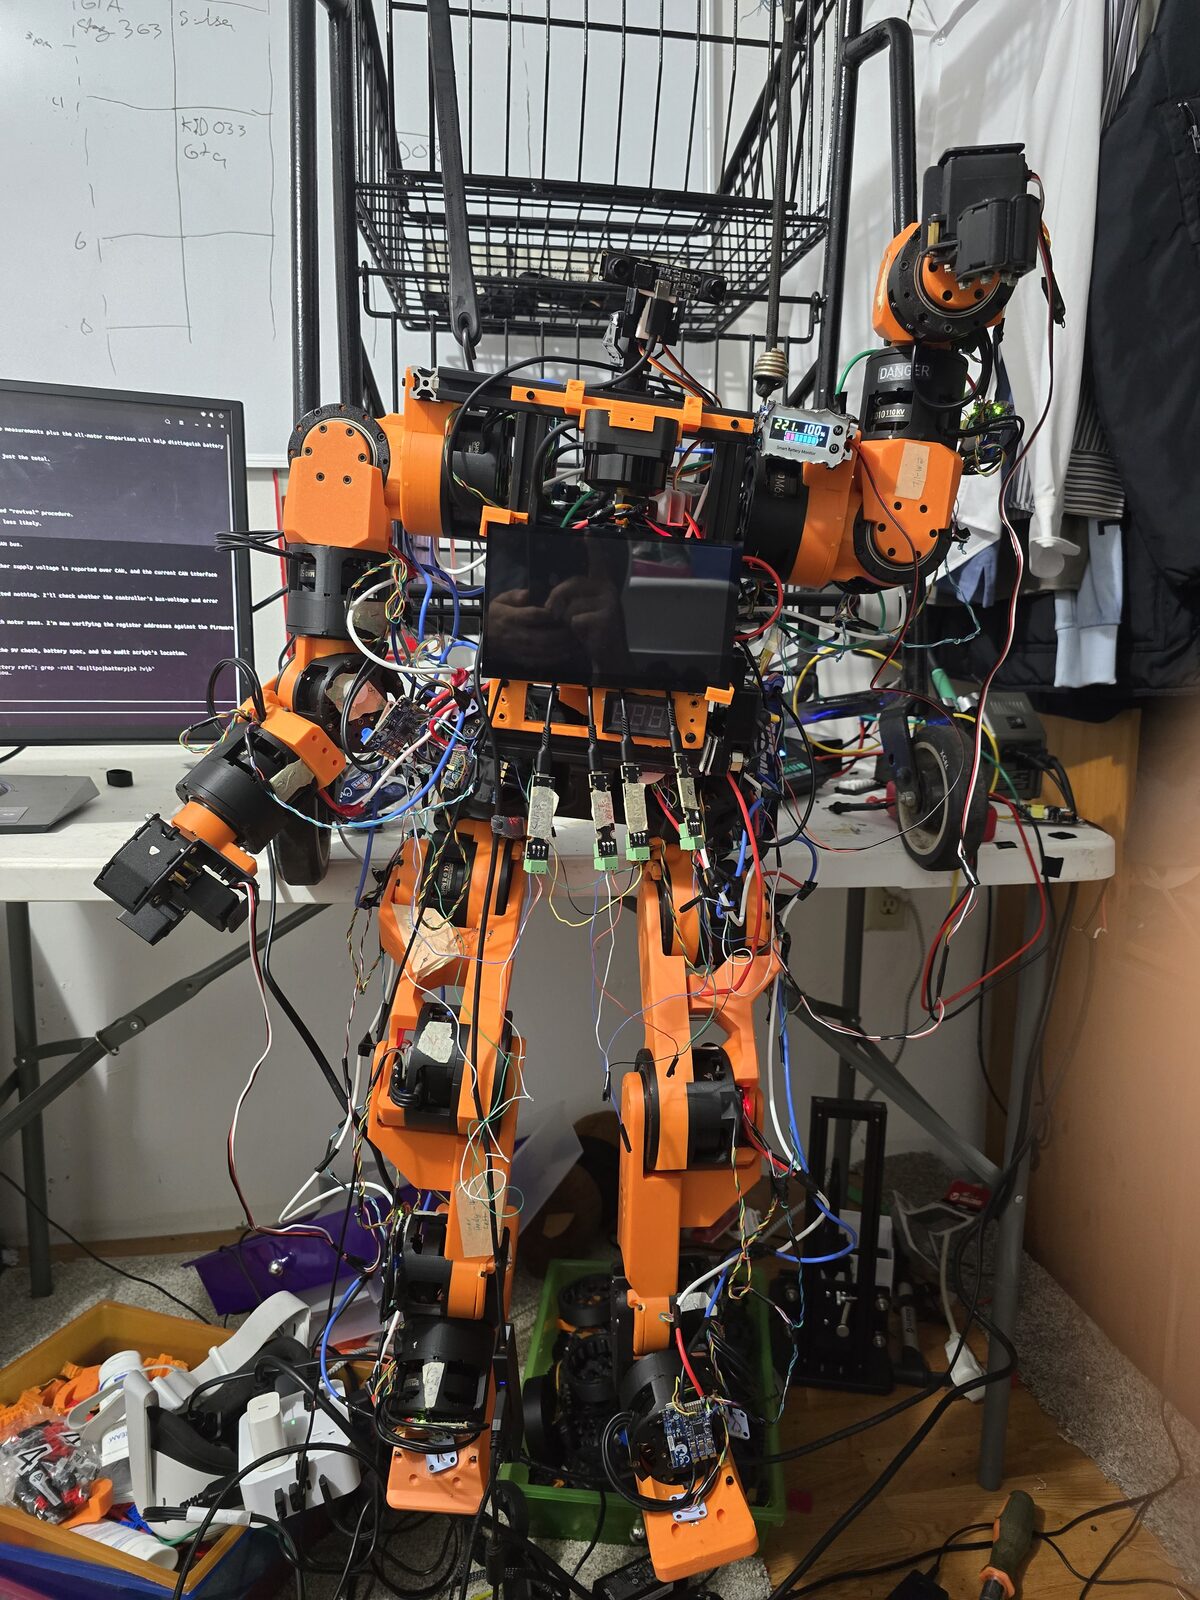
26 12 Sep — Fully built. Working on getting movement. -
27 13 Sep — First sign of life.
Soldering 22 AS5600 magnetic encoders onto B-G431B-ESC1 controllers took two full days. It was also my first time soldering.
Funded by hard work and sheer determination: about $6k in parts, paid for with 80-hour weeks. I came into it oblivious about the time and the cost, but once I'd committed to the printer I decided not to back down.
The original goal was a fully tele-operated robot driven by an Oculus headset before the convention. Midterms, 2,000+ M3 inserts to count, and a few DIY 3D-printer repairs meant the project needed an extension.
This is my build of Berkeley Humanoid Lite, the open-source 3D-printed humanoid from the Hybrid Robotics Lab at UC Berkeley. The design files, assembly documentation and the RSS 2025 paper behind it all live upstream: